Tottori Rover Challenge 2026
Tottori Rover Challenge 2026
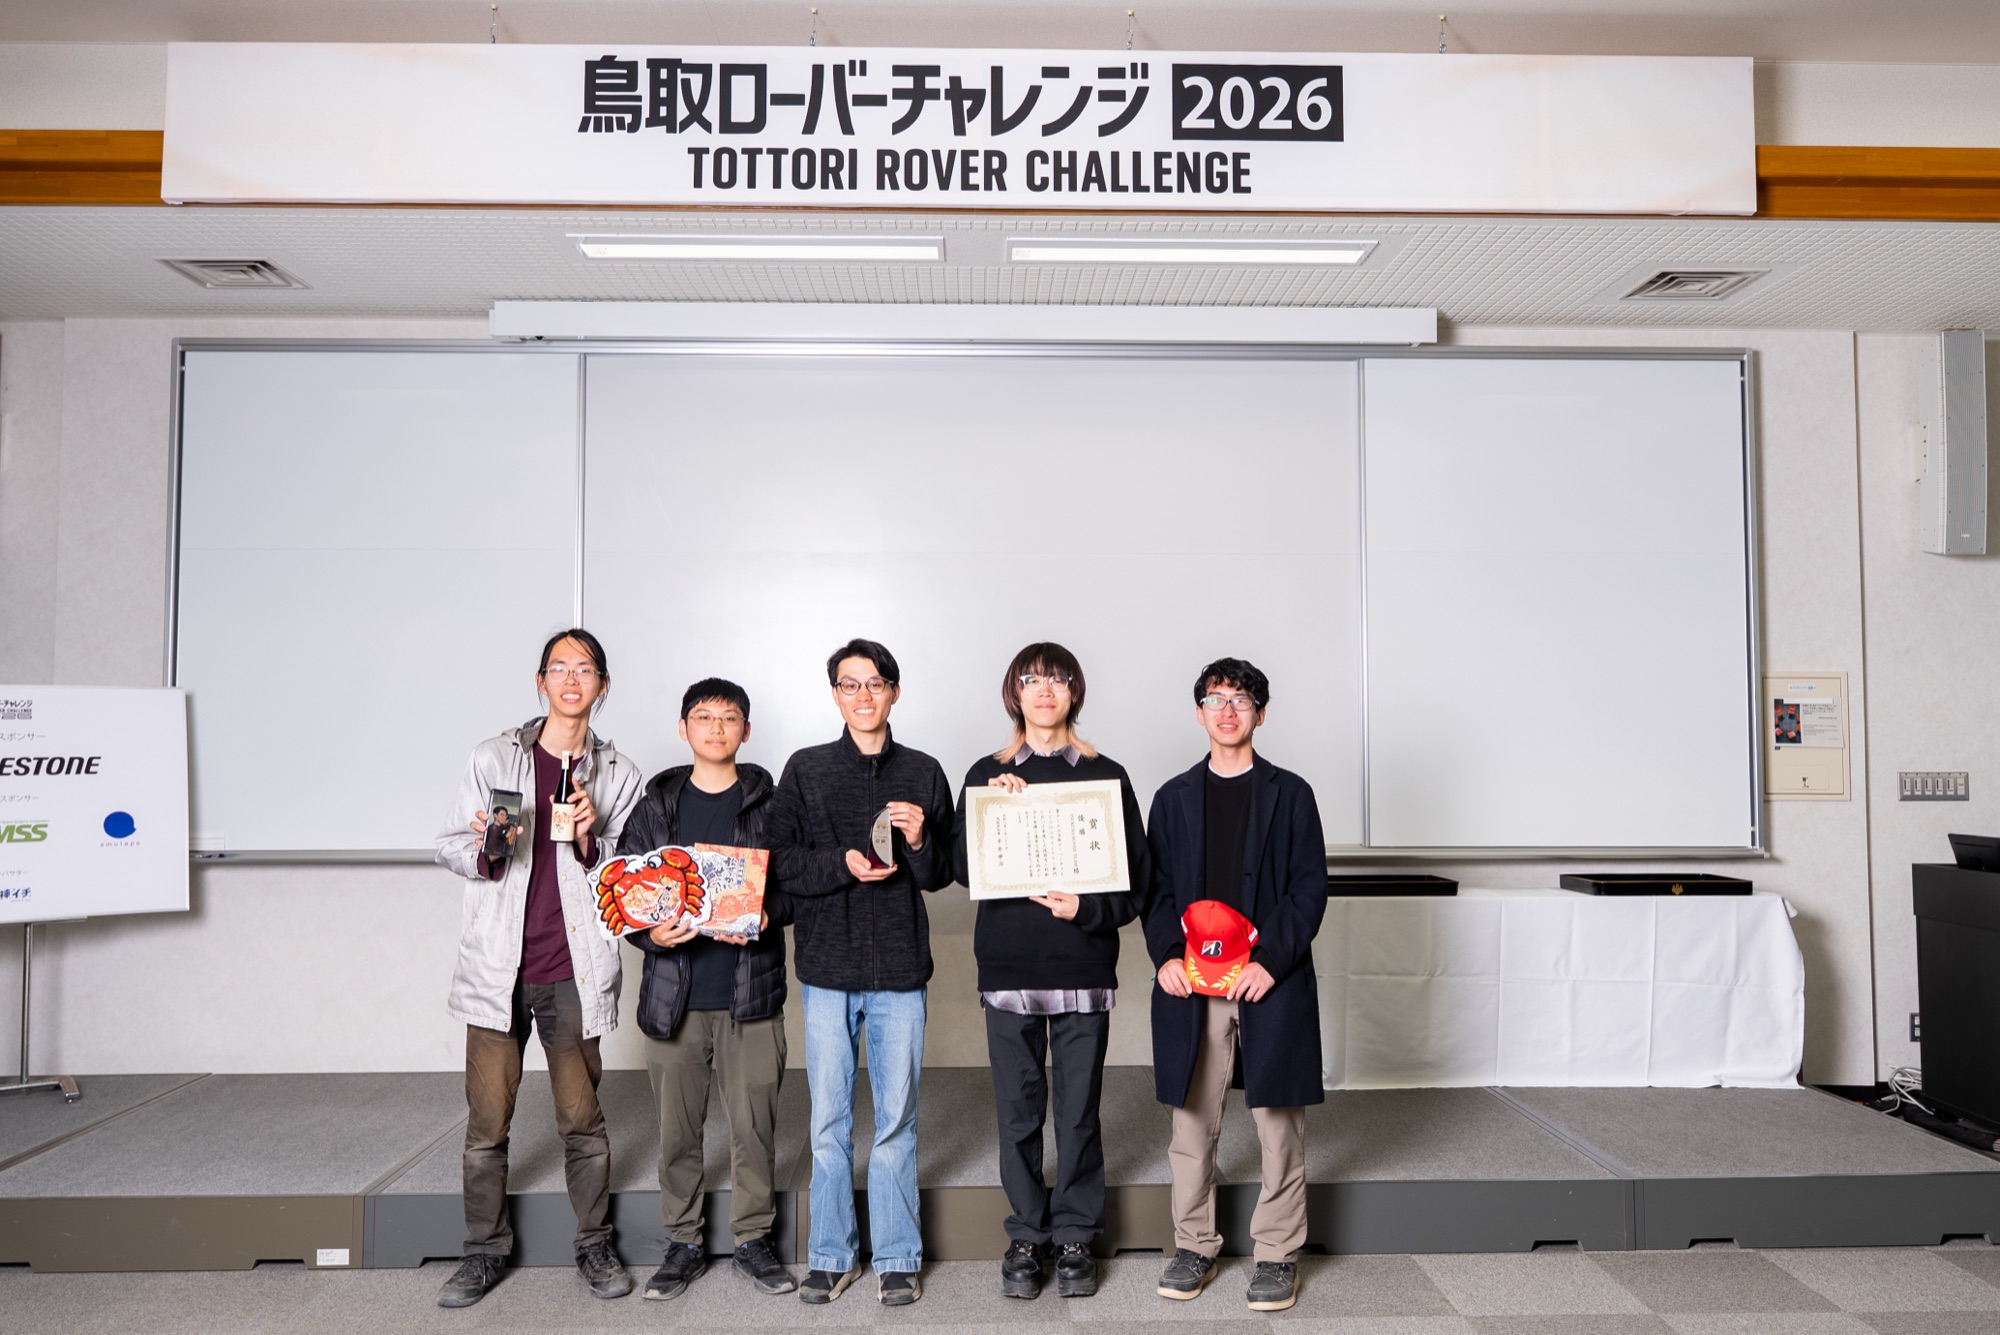
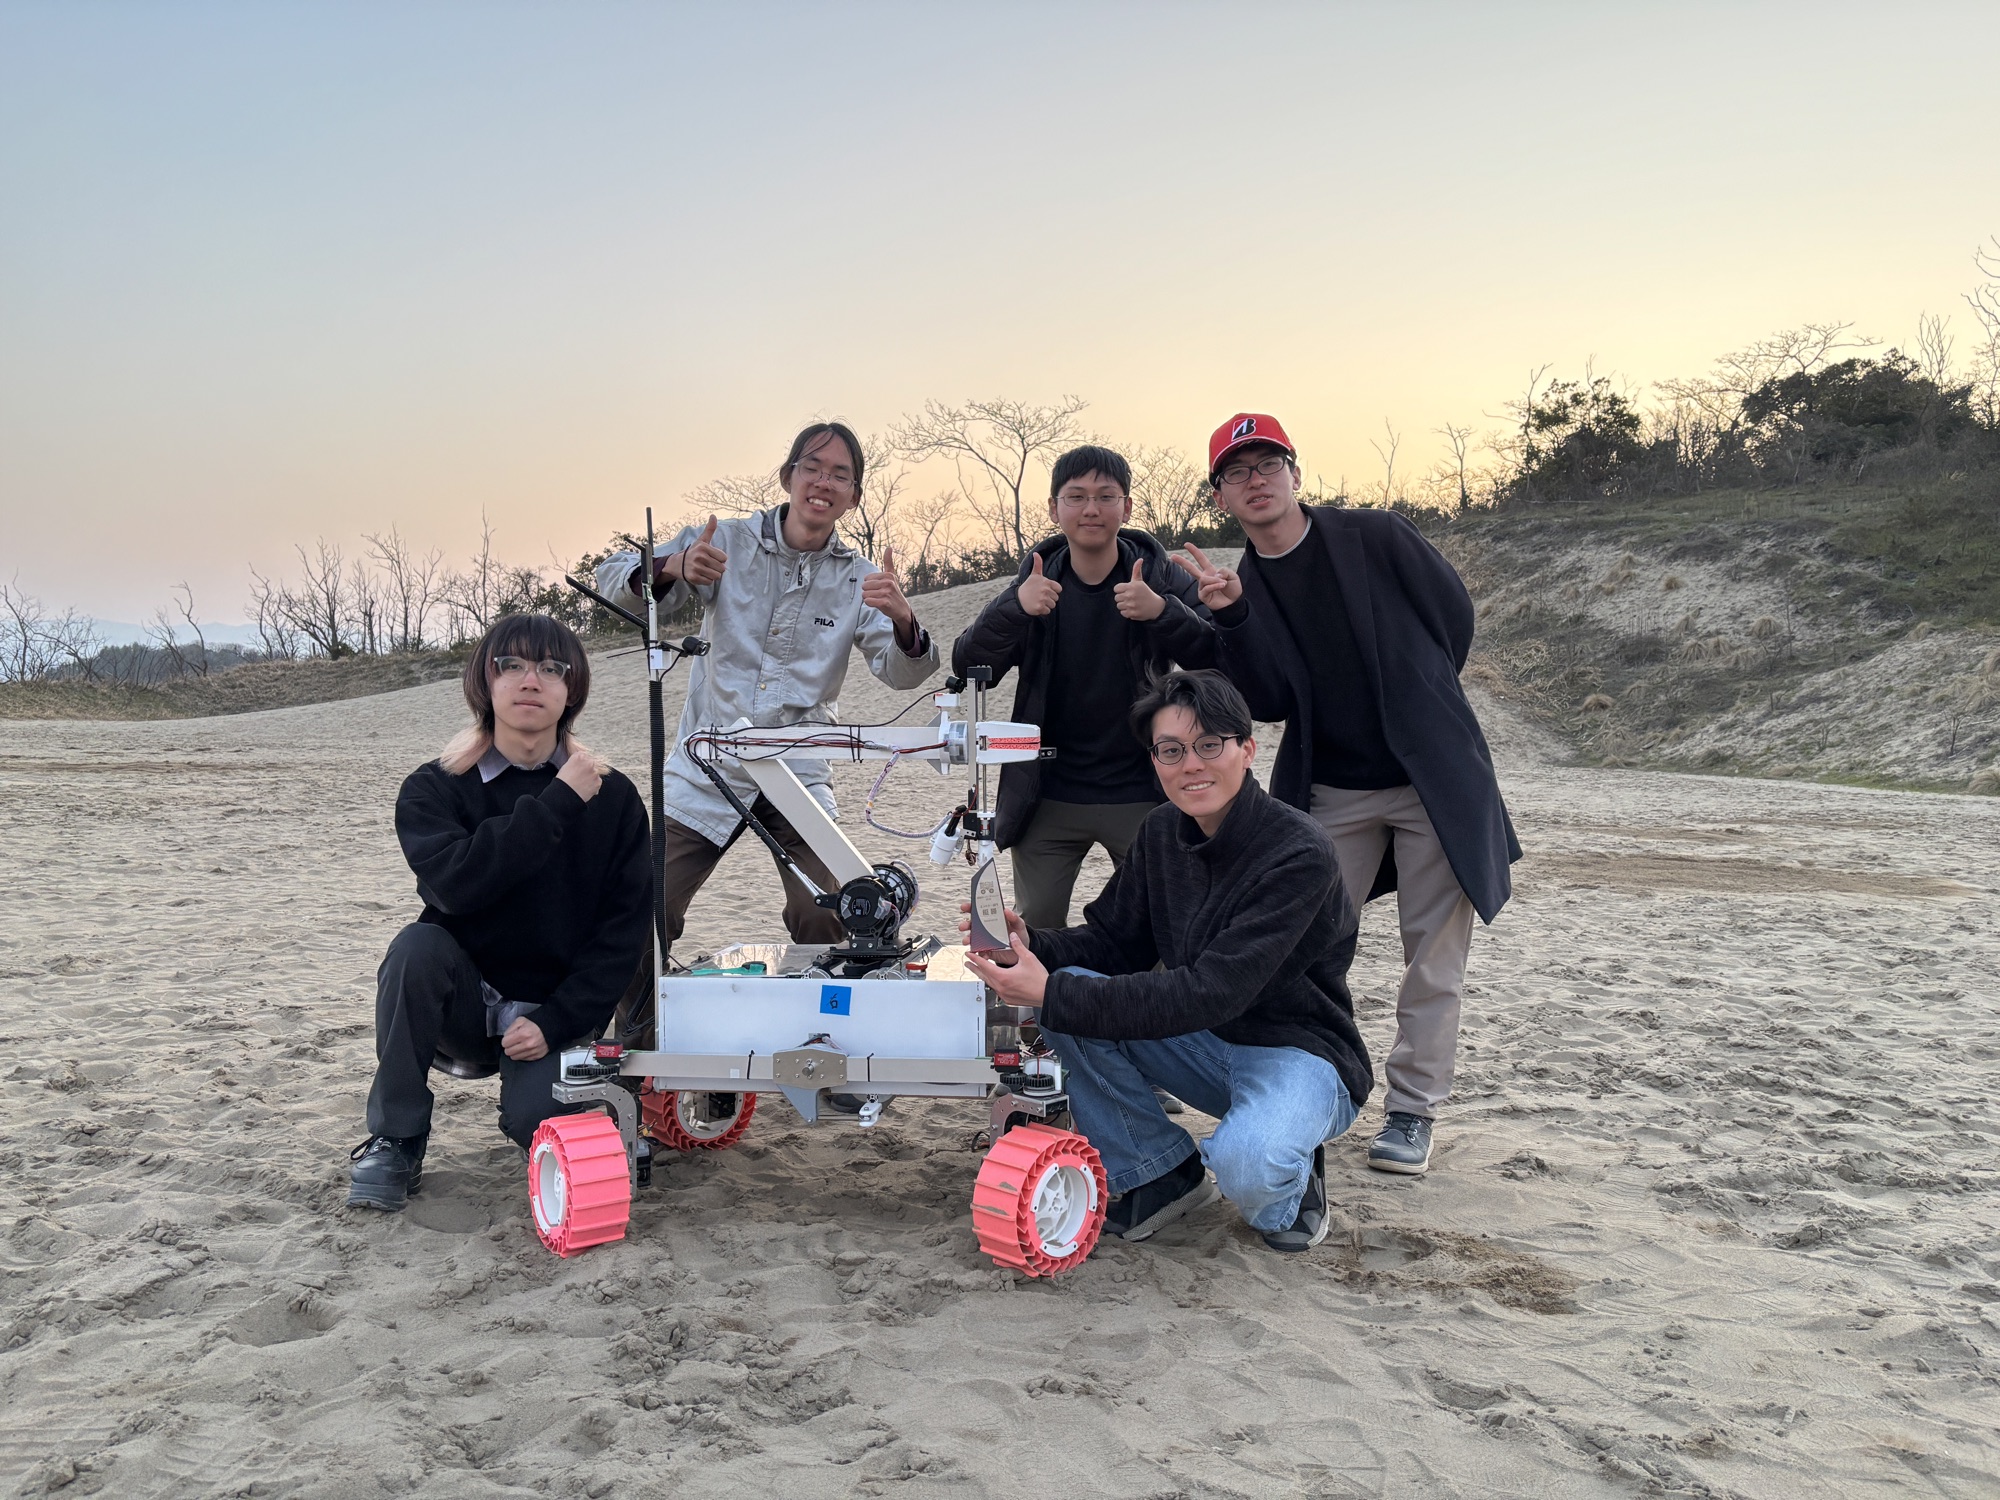
Entry Division winner. A record of three days in the Tottori Sand Dunes with our first rover, TR-1.
Result
From 1st in qualifying to winning the final
In our first appearance at a competition with 23 teams, we scored in all three missions (scientific exploration, autonomous driving and unmanned construction), finished the qualifying round 1st overall, including professional teams, and advanced to the final. In the final we carried a 5 kg steel ball all the way without dropping it once, and passed every waypoint in autonomous driving, winning the Entry Division.
Winner
Final
Entry Division
1st
Qualifying round
Overall, including professional teams
Scoreboard
Scoreboard
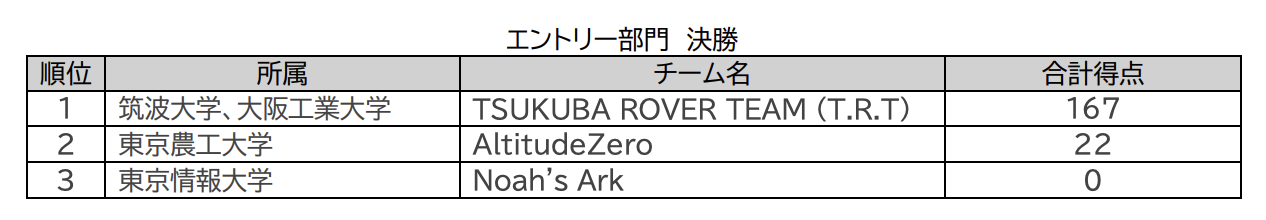
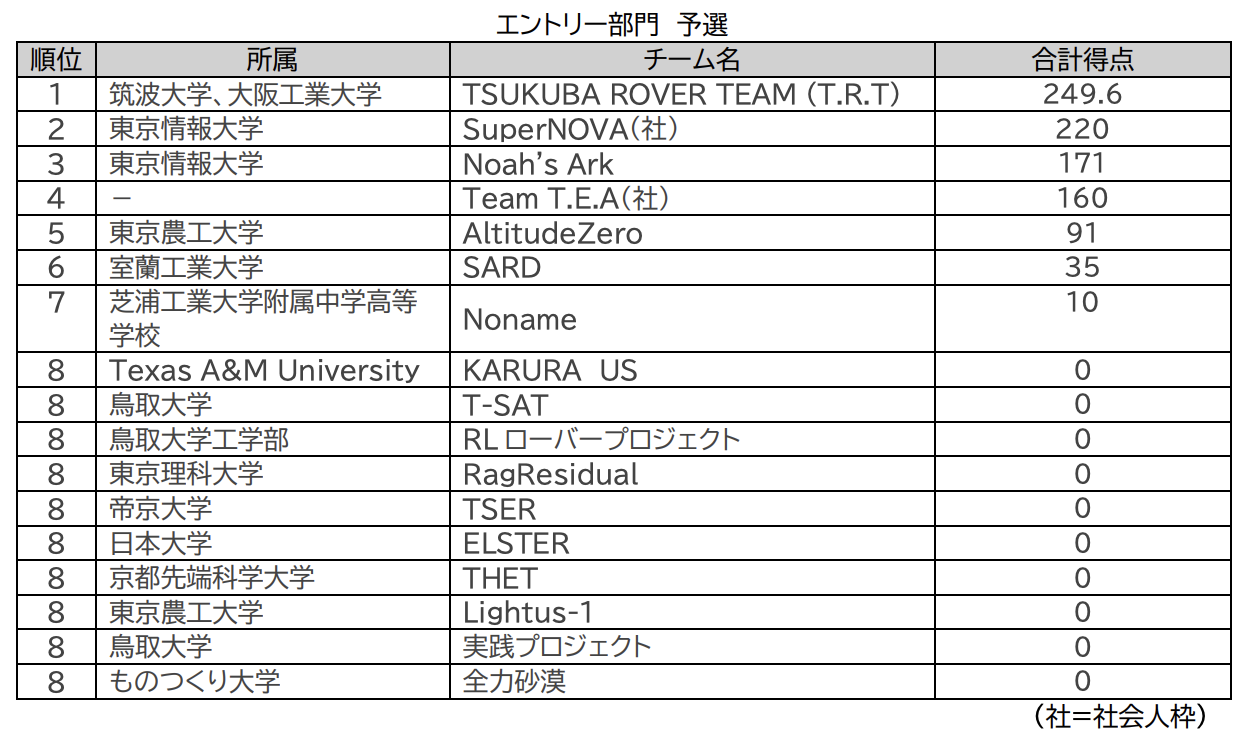
Entry Division results from the official final results (Pro = professional team).
Final
Final
1
TSUKUBA ROVER TEAM
167
2
AltitudeZero
22
3
Noah’s Ark
0
Qualifying
Qualifying round (top 5 of 17 teams)
1
TSUKUBA ROVER TEAM
249.6
2
SuperNOVA (Pro)
220
3
Noah’s Ark
171
4
Team T.E.A (Pro)
160
5
AltitudeZero
91
View the official results (images)
Tap (click) an image to open it at full size in a new tab.
About
On a lunar test field in the sand dunes,
teams compete in planetary exploration technology.
The Tottori Rover Challenge is held at Luna Terrace, a planetary exploration test field in the Tottori Sand Dunes, where teams compete in the technologies needed for scientific exploration and base construction on other worlds. It has an Entry Division focused on core rover technology and completing missions, and an Expert Division with more advanced autonomy and complex tasks. We competed in the Entry Division.
Dates
March 19 (Thu) – 21 (Sat), 2026
Venue
Luna Terrace, planetary exploration test field, Tottori Sand Dunes (within the Arid Land Research Center, Tottori University)
Organizer
Tottori Rover Challenge Executive Committee
Division
Entry Division
Rover
Our first rover, TR-1
Missions
Three competition missions
In the qualifying round, teams are ranked by their total score across three missions, and the top teams advance to the final. The final has two stages: a combined scientific exploration and unmanned construction mission, and autonomous driving. You can watch TR-1 in action in the videos below (no audio).
01
Scientific exploration
Teams operate switches on a lander and pull out its power plug, photograph rocks, measure sand temperature, and climb a slope of over 20 degrees to take wide-area images from the top.
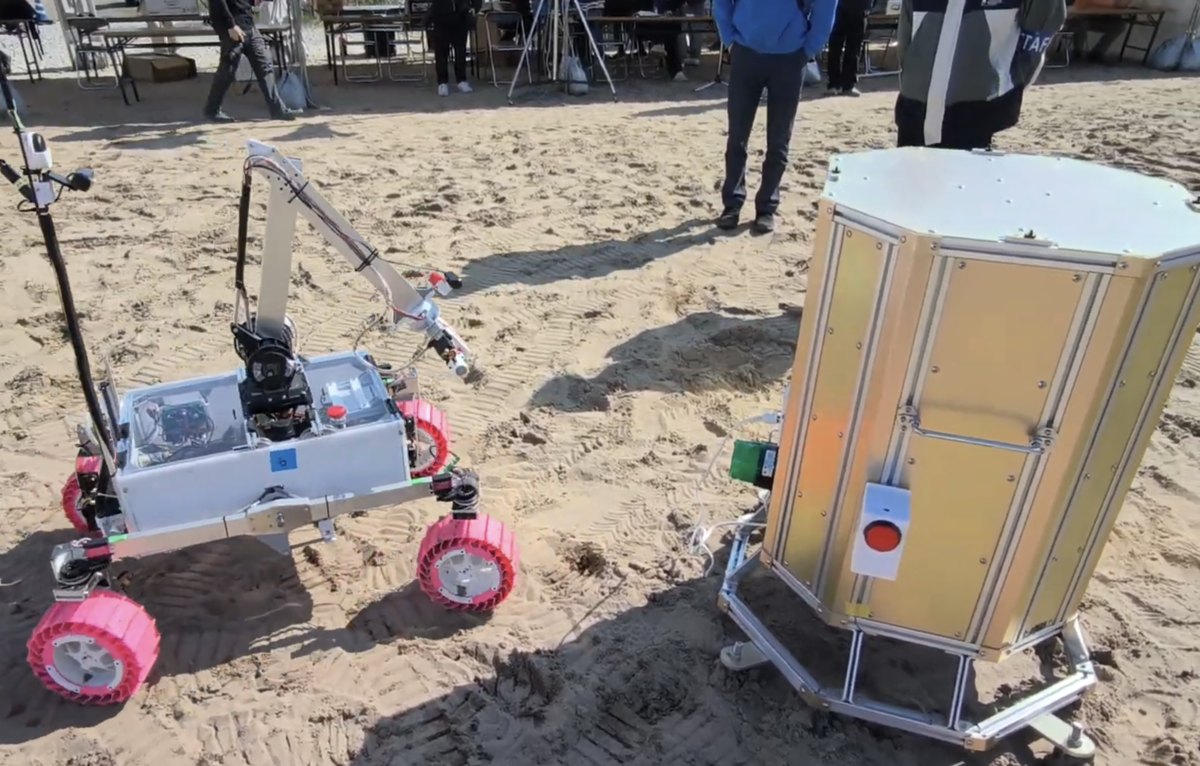
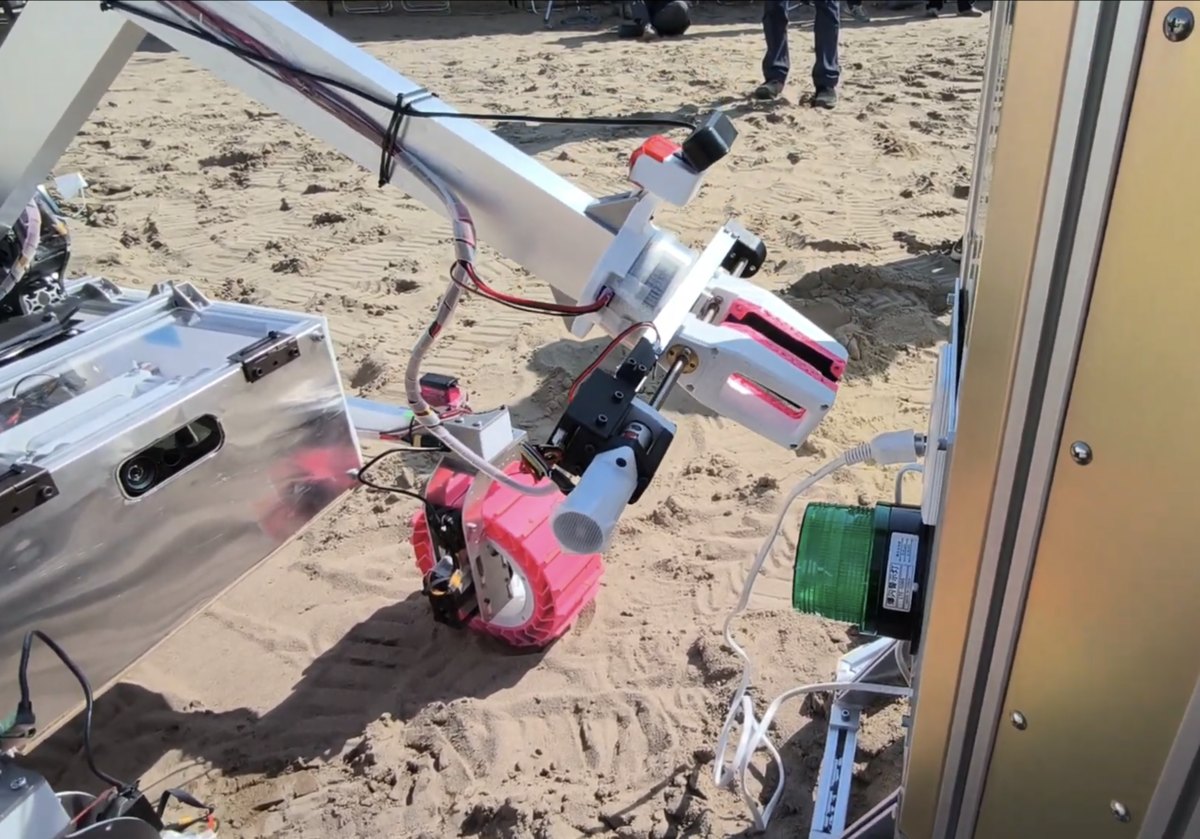
Using the arm, we pressed the lander's power button and pulled out the plug.
02
Autonomous driving
Without human control, the rover uses only its sensors and control program to avoid obstacles, pass through designated waypoints and reach the goal.
With a program rewritten just before the competition, the rover passed every waypoint autonomously in the final.
03
Unmanned construction
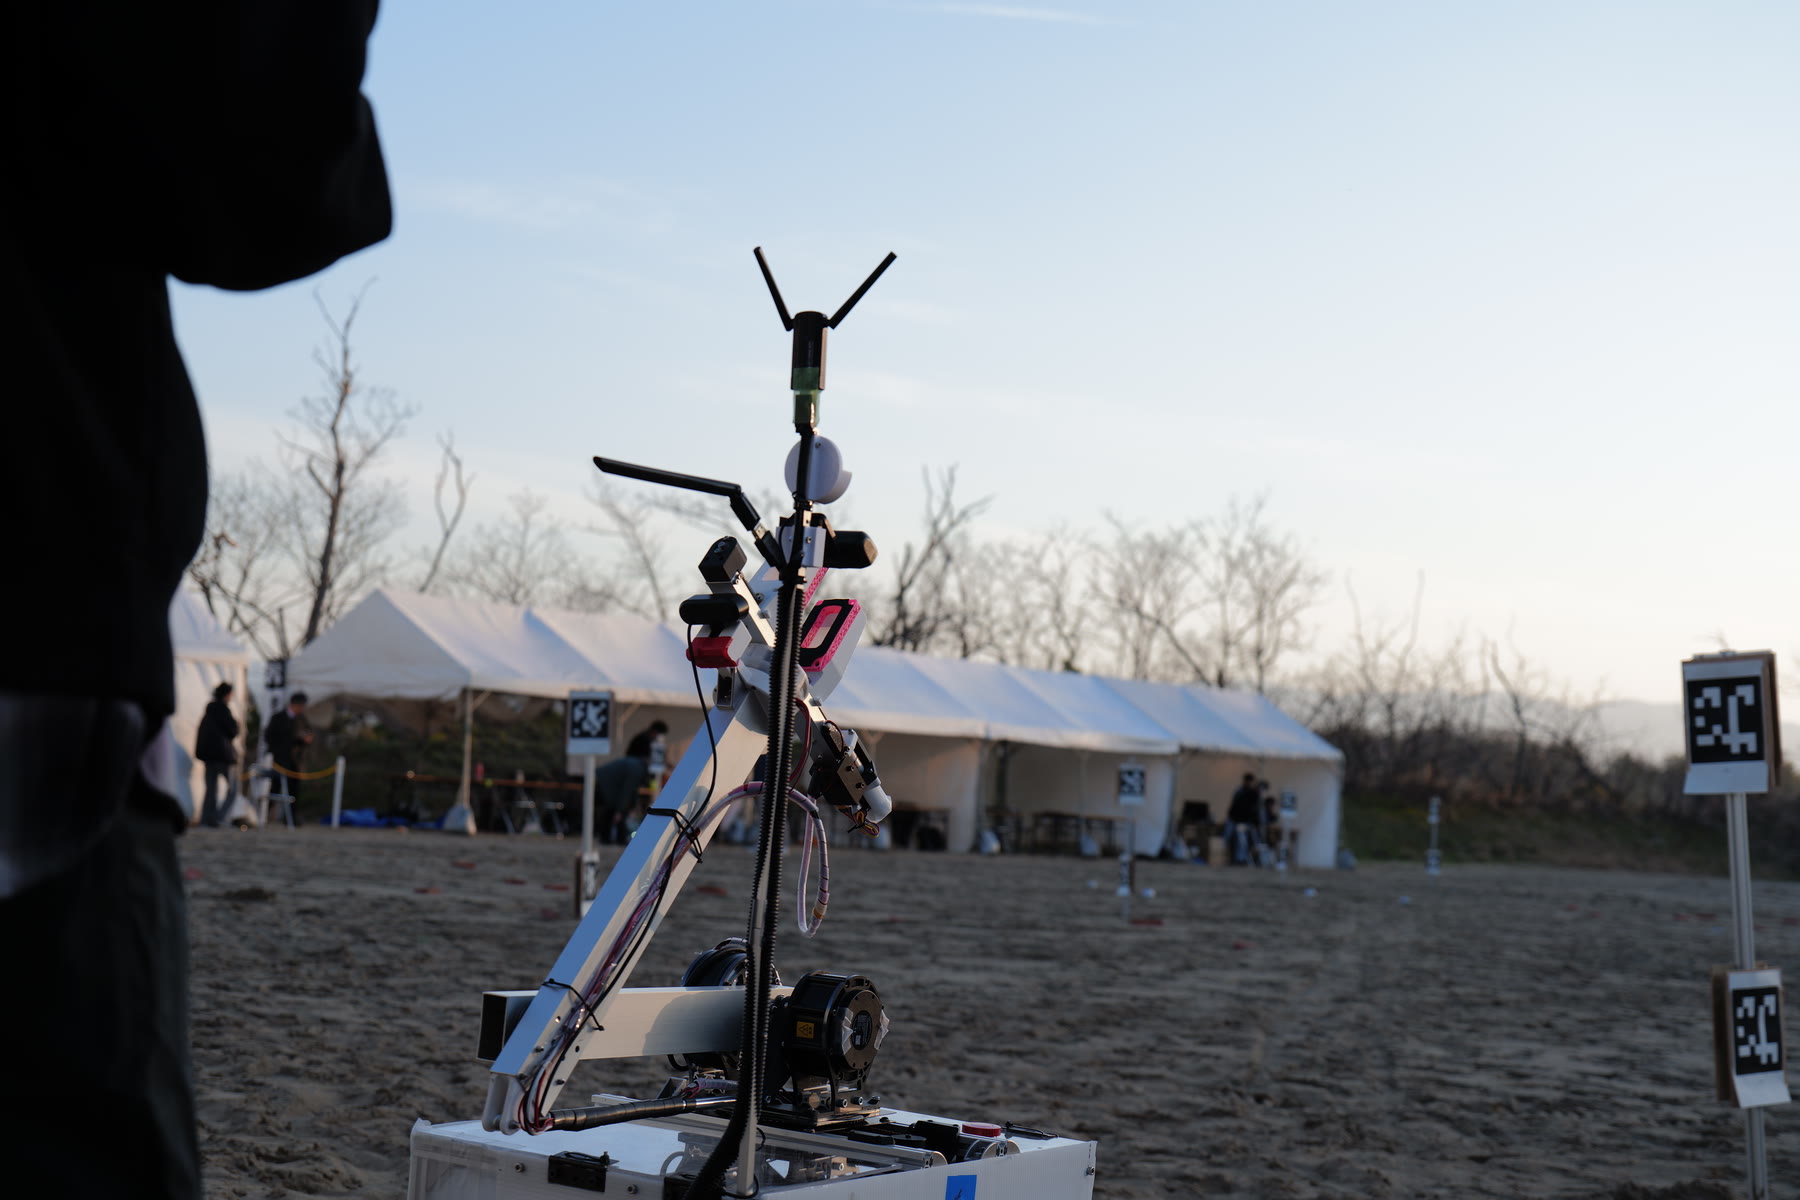
Teams grab and carry building materials such as a 5 kg steel ball with the arm, and also deploy an antenna and carry out a surveying task by reading ArUco markers.
In the final, our 5-axis arm gripped the 5 kg steel ball and carried it all the way without dropping it once.
Science Team
Science
Our science team examines the surface images sent back by the rover, interprets the composition and formation of rocks from them, and reports the findings. They also measured underground temperature, supporting our score in the scientific exploration mission, which cannot be earned by driving and operation alone.
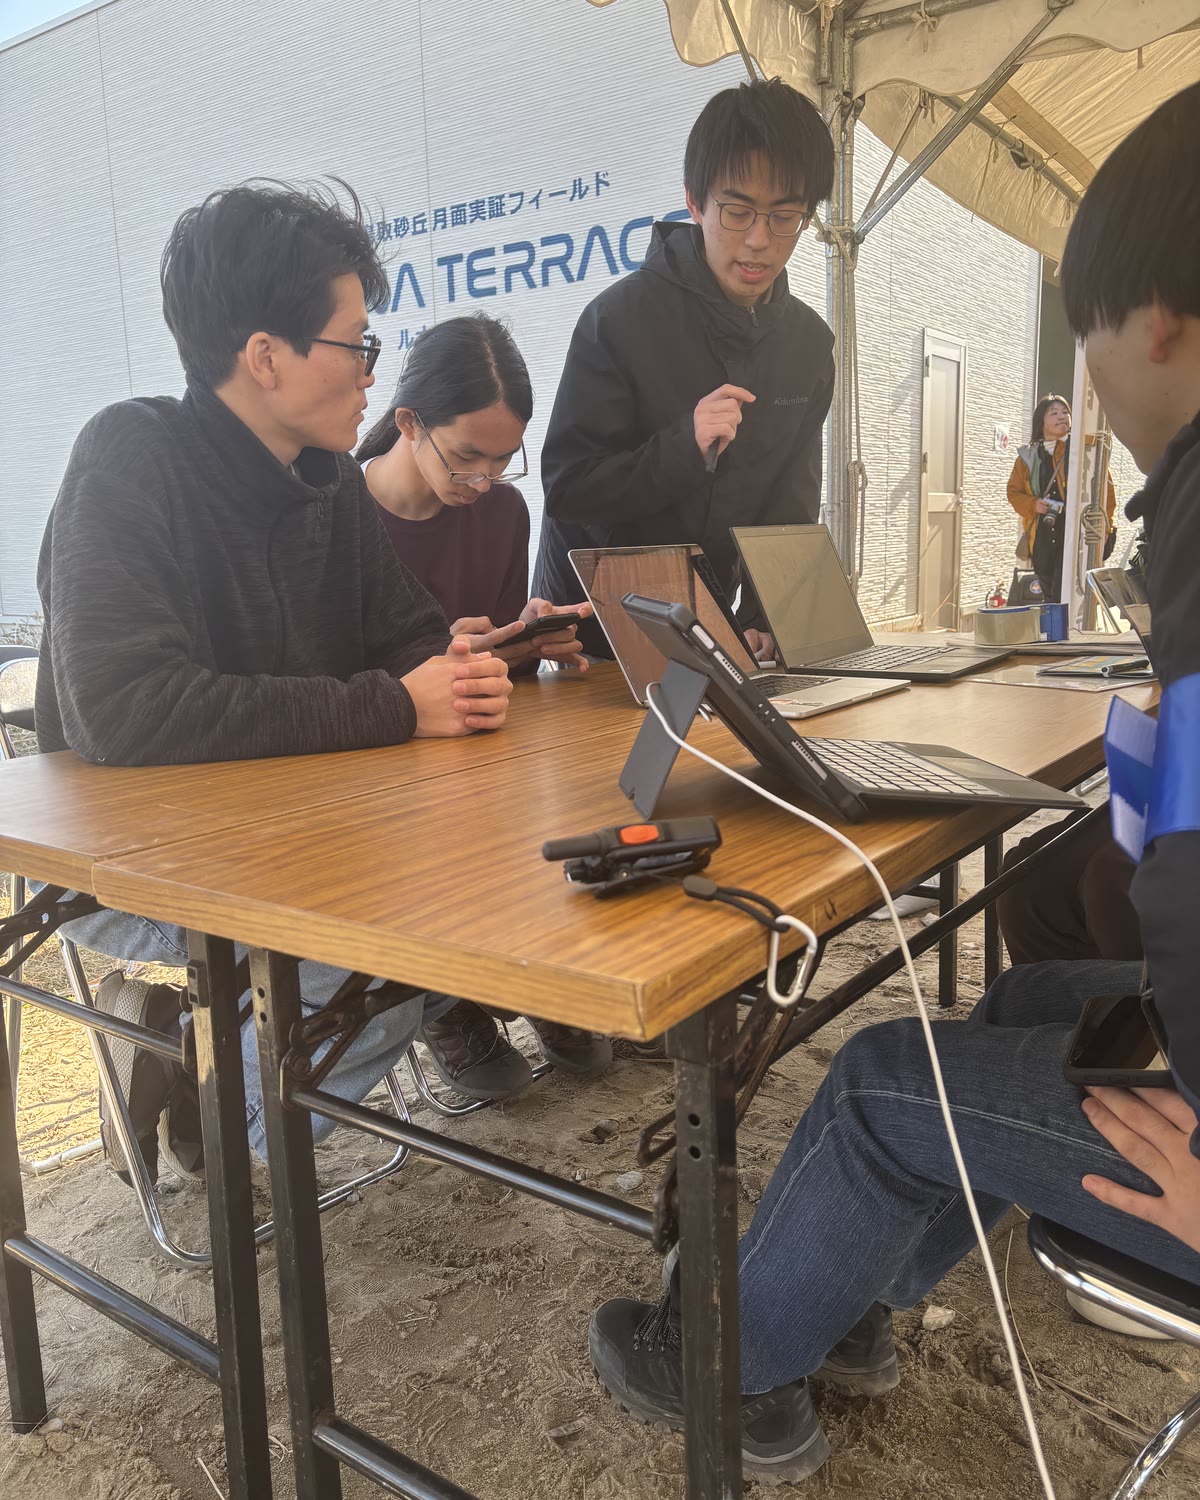
Reporting the results
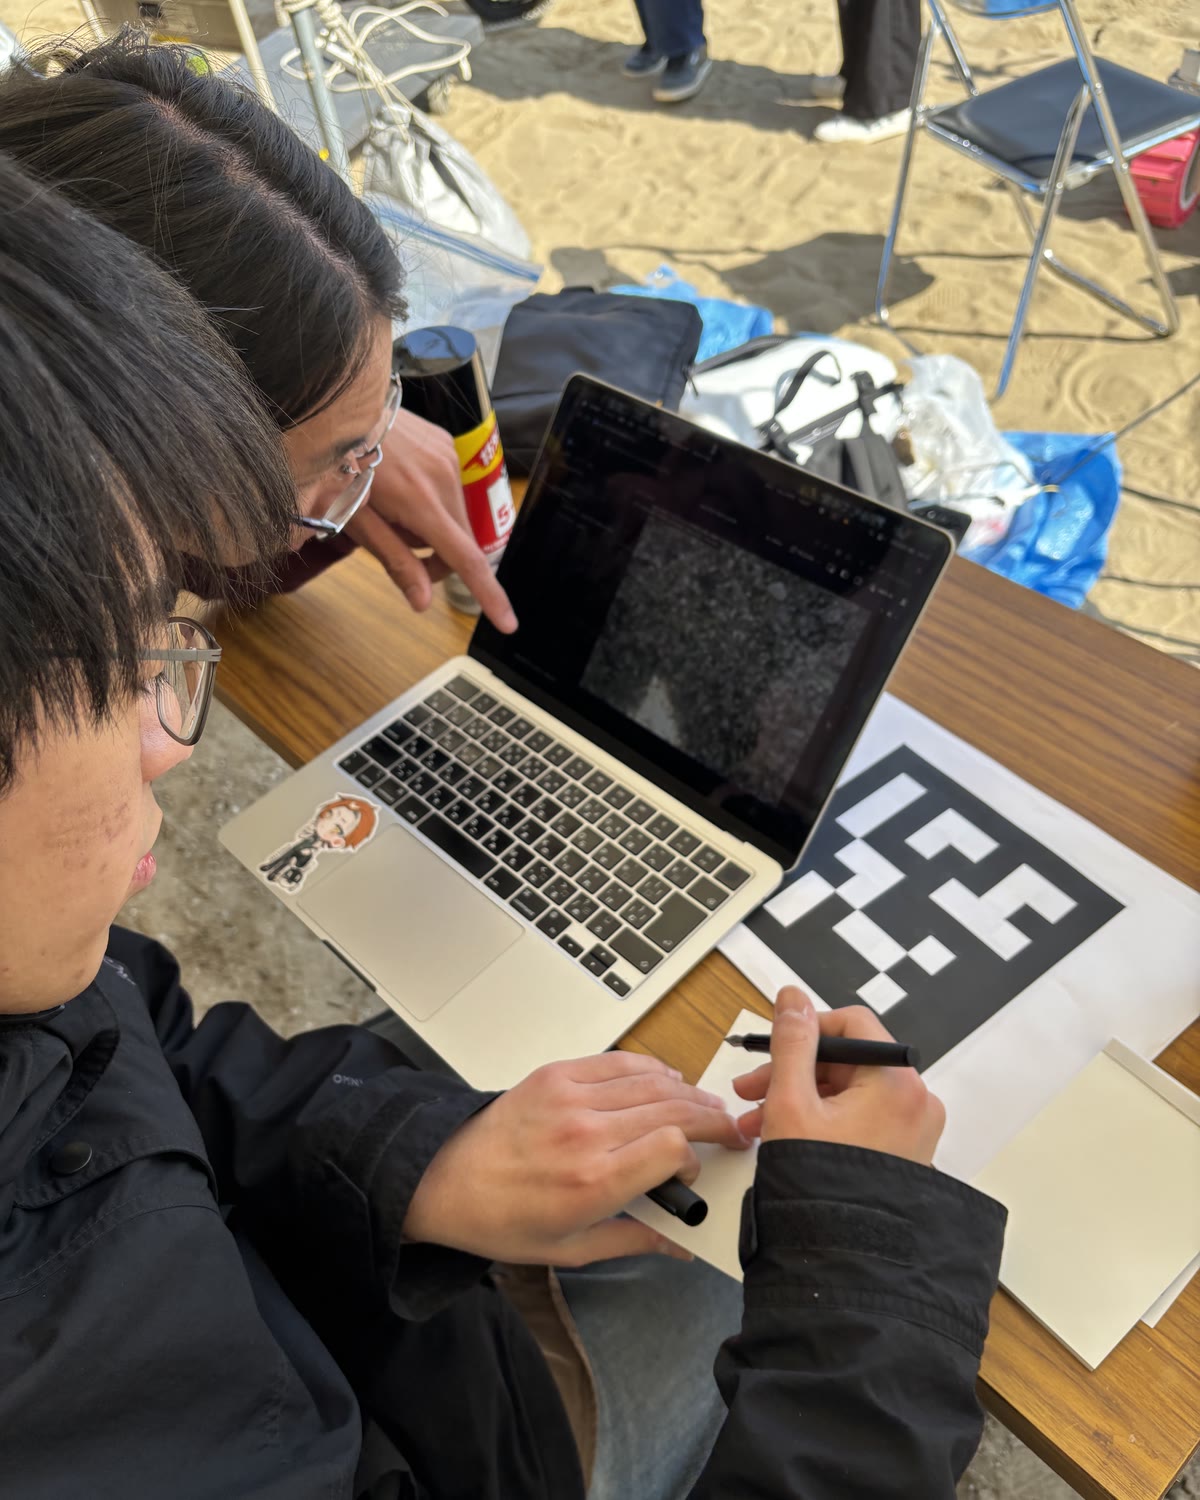
Analyzing the images
From observation to report
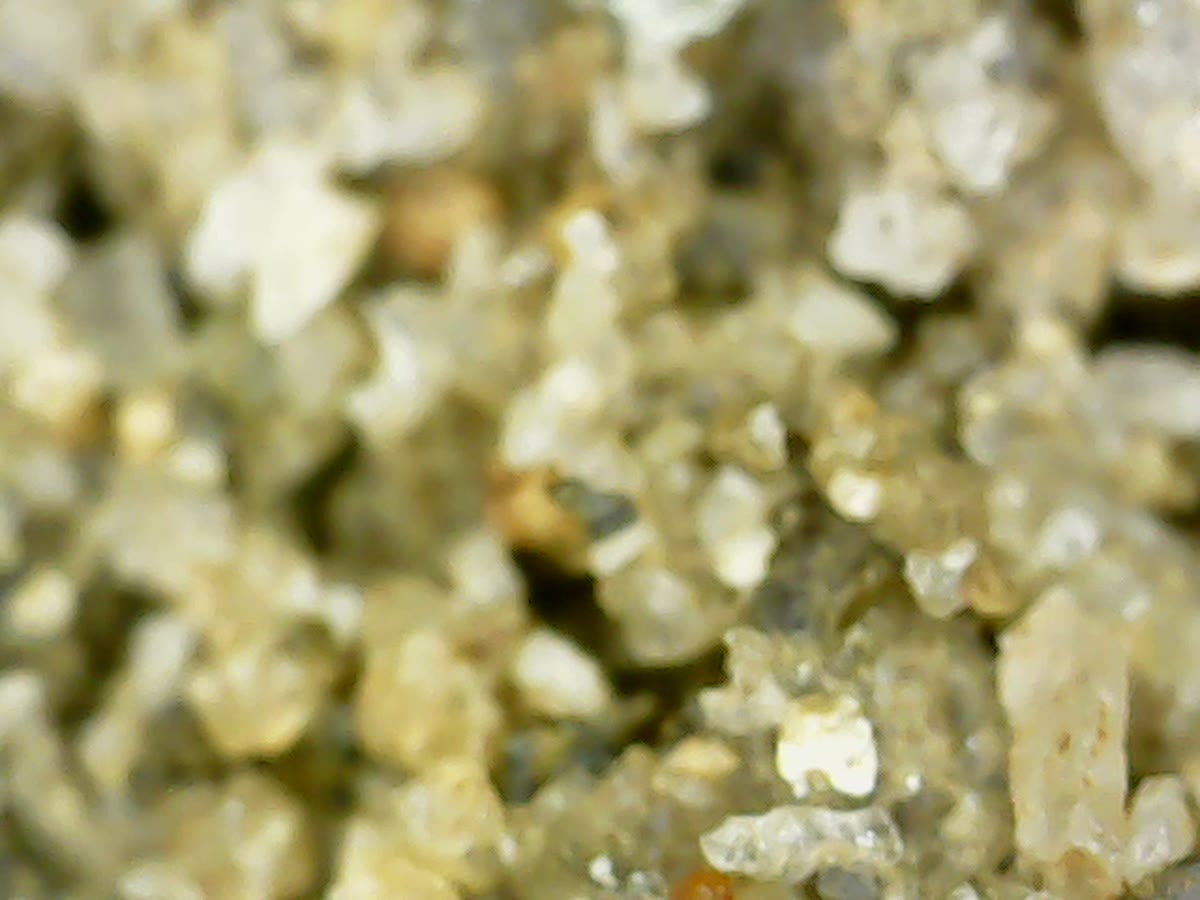
Sand grains from the imaging test
01 — Preparation
Imaging test before the competition
Before the competition, we tested imaging sand with a digital microscope and confirmed that we could capture images clear enough to tell individual grains apart.
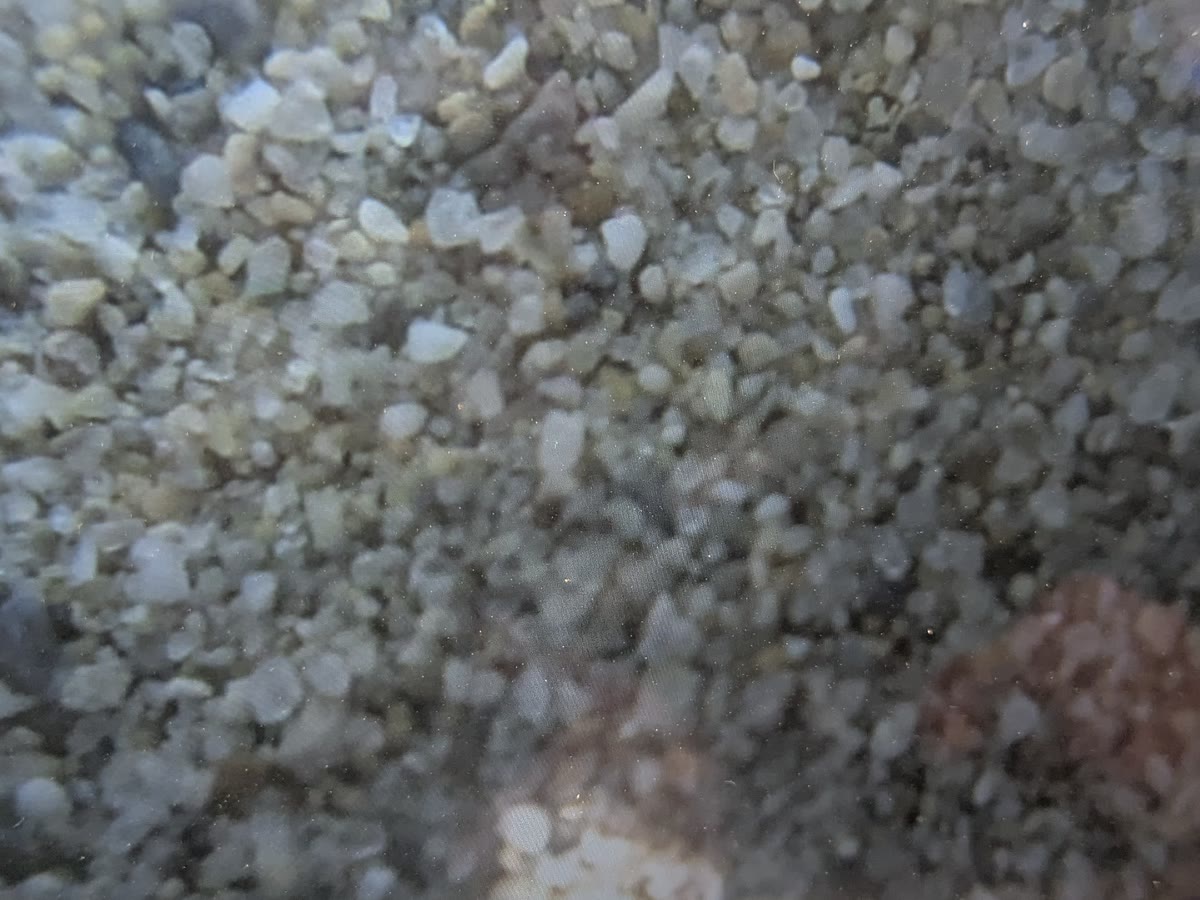
Magnified view of sand sent from the rover
02 — Qualifying
Qualifying: observing the surface and underground
We successfully photographed rocks, measured the temperature of the sand surface and at 5 cm depth, and imaged sand with the microscope scope.
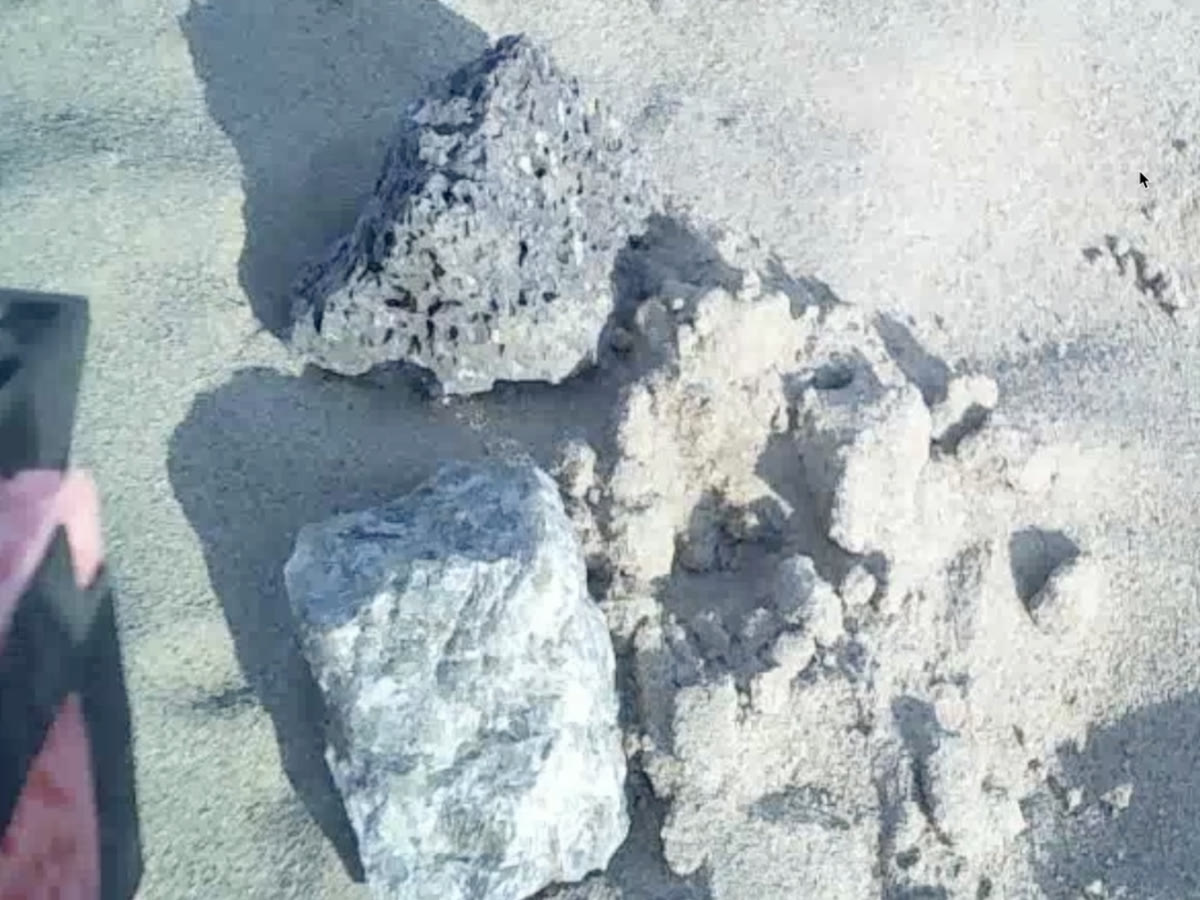
A rock captured by the camera on the arm tip
03 — Final
Final: rebuilding the equipment
For the final, we removed the observation module and mounted a camera on the tip of the arm. We designed, fitted and wired it on site, printing the parts on the 3D printer we brought with us.
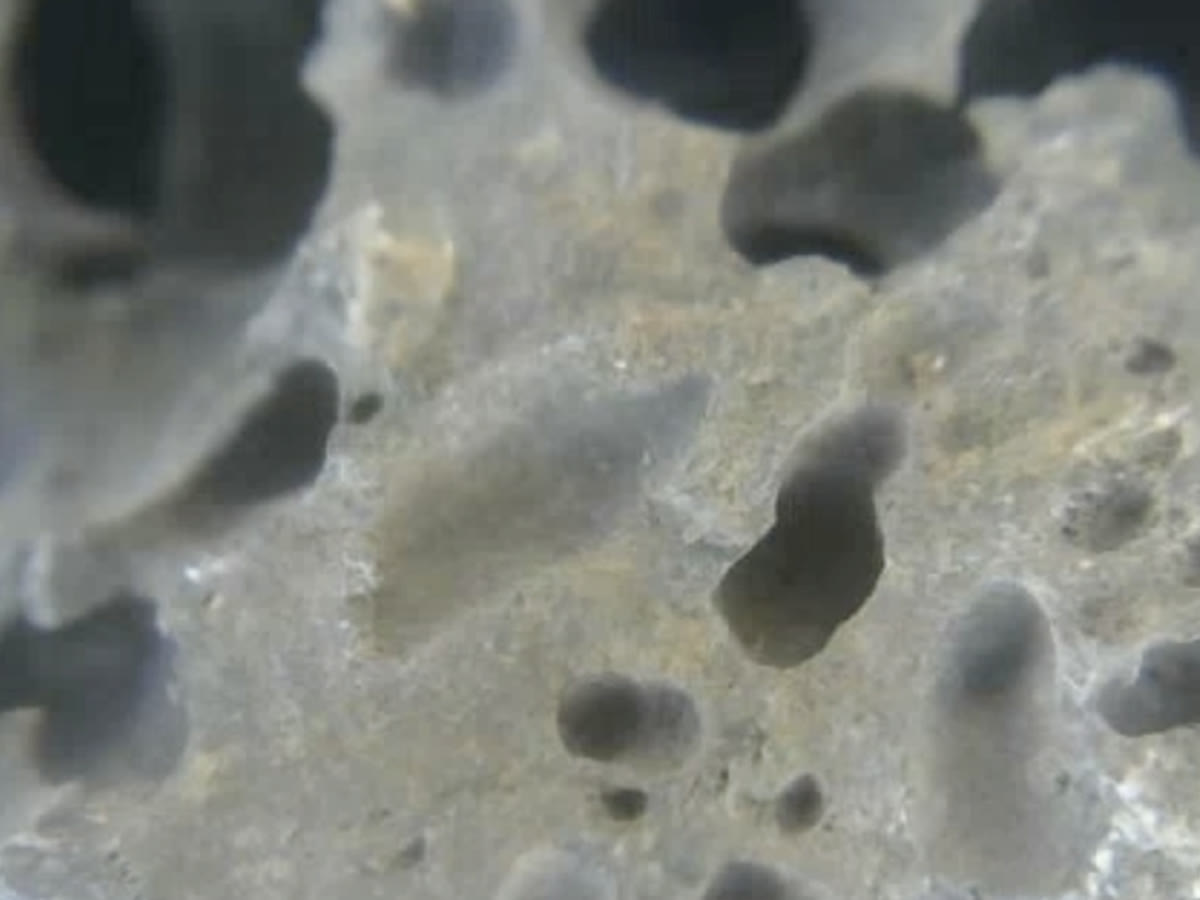
Magnified image of a rock surface
04 — Report
Report: interpreting the data
From the surface images, we inferred the composition and formation of the rocks and reported them to the judges together with the underground temperature data. The quality of the discussion is also scored.
Interview
Winners' interview
Together with ARES Project, winner of the Expert Division, we appeared on a stream by competition ambassador Tsukimegami Ichi and talked about our road to victory and the story behind building our rover.
Rover
Rover
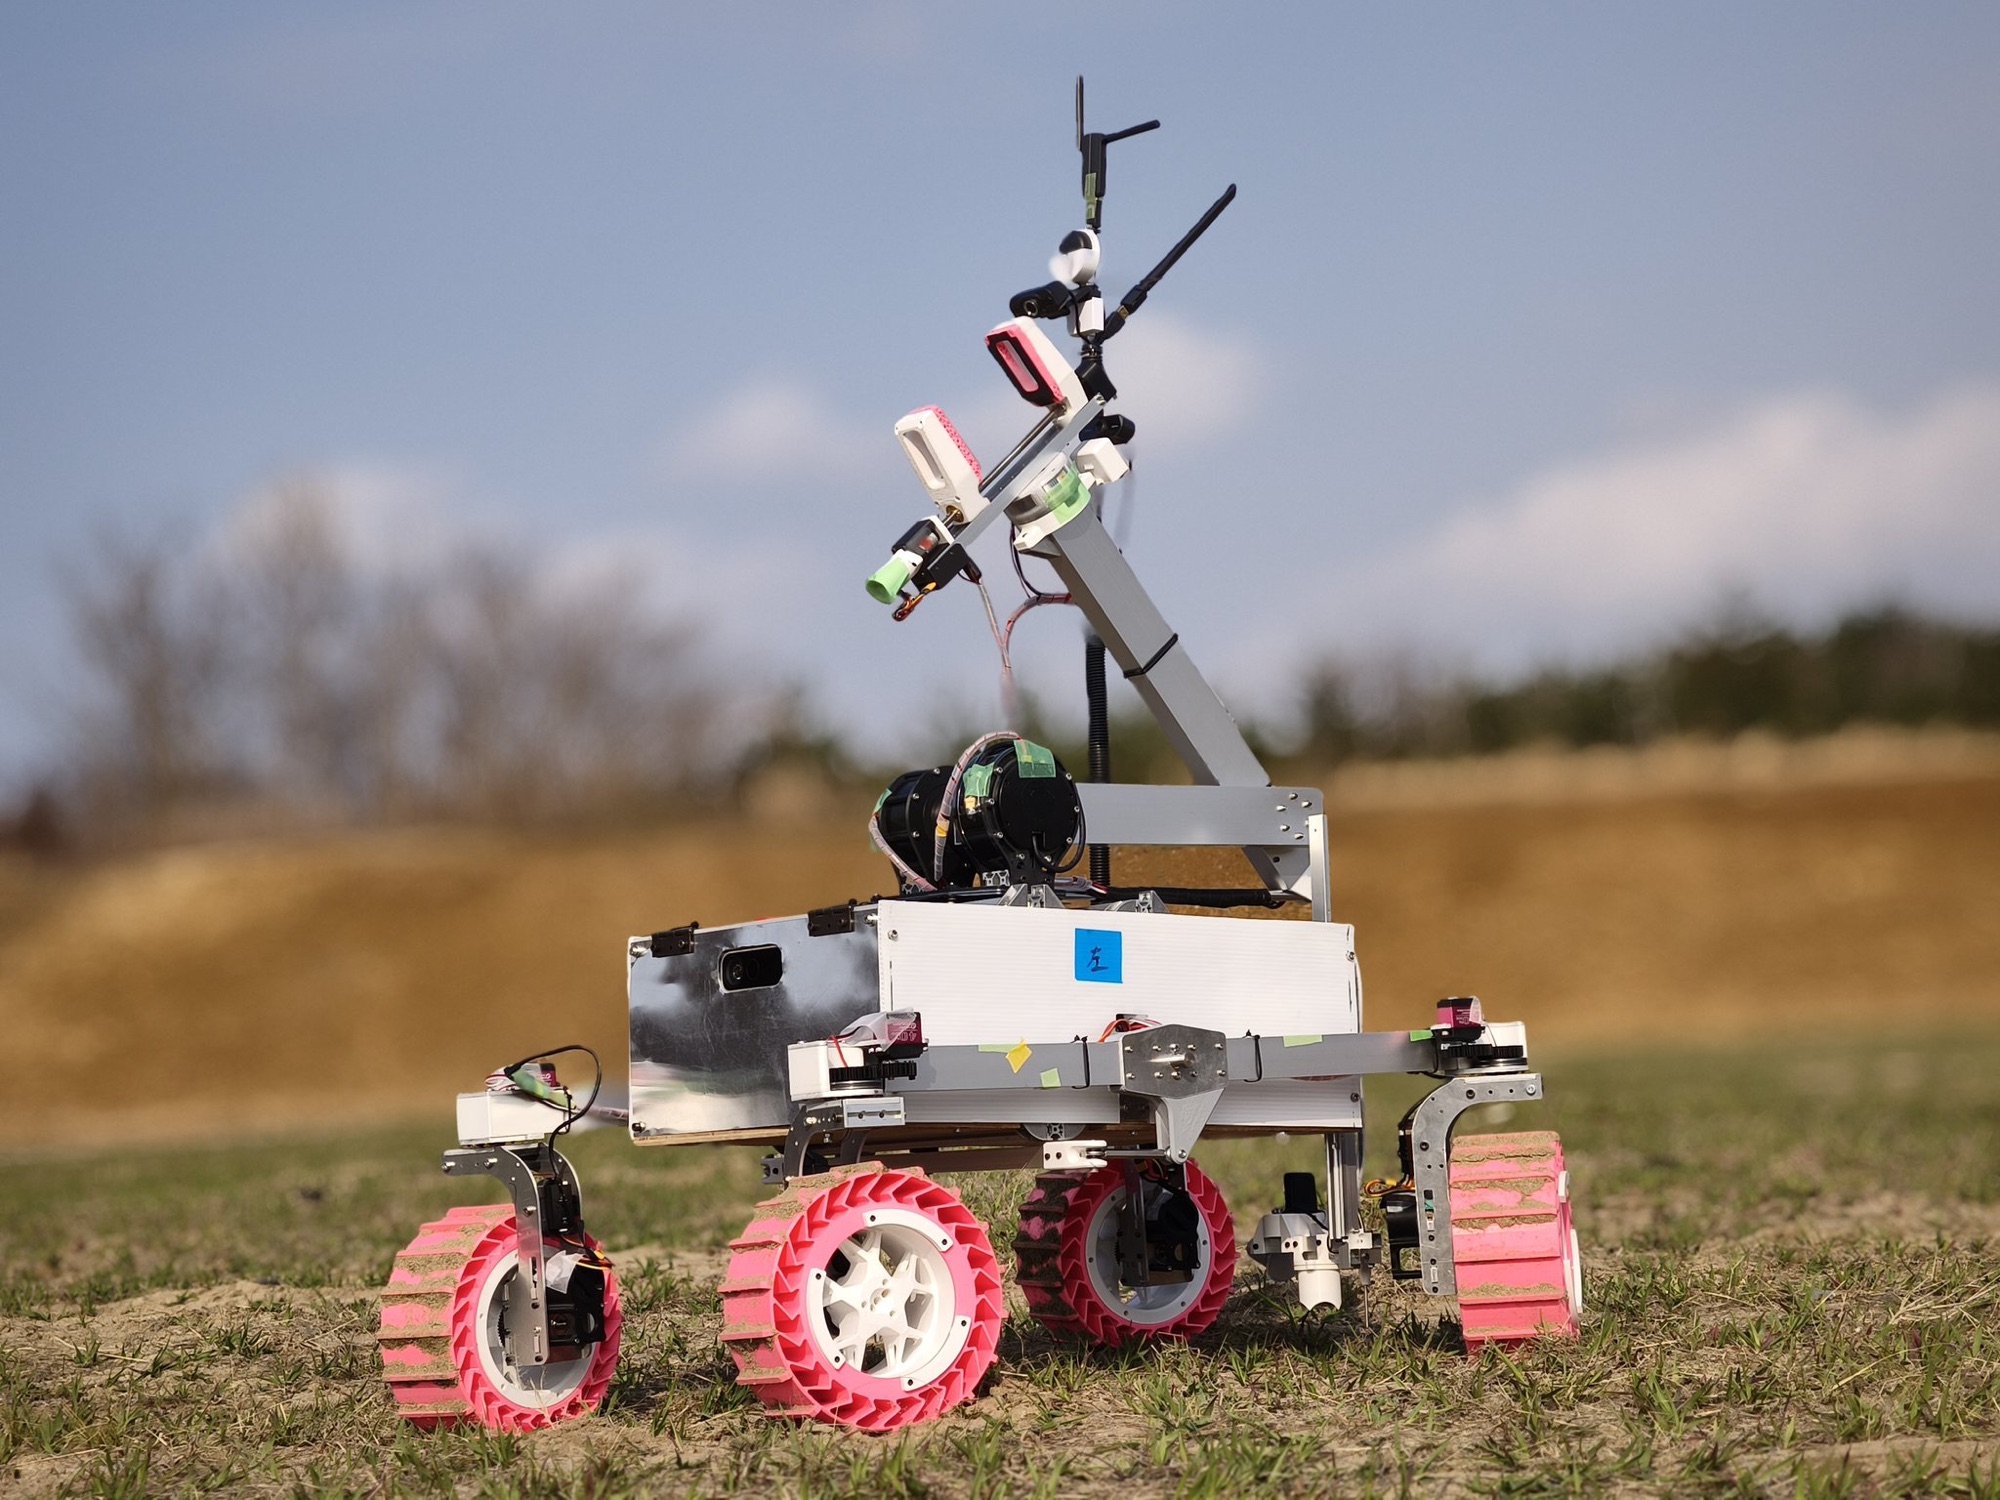
Rover 01
Our first rover, TR-1
4-wheel independent steering, a 5-axis arm and 5 GHz communication. Details of our first rover, developed in about six months.
Story
Competition log
2026.03.14–15
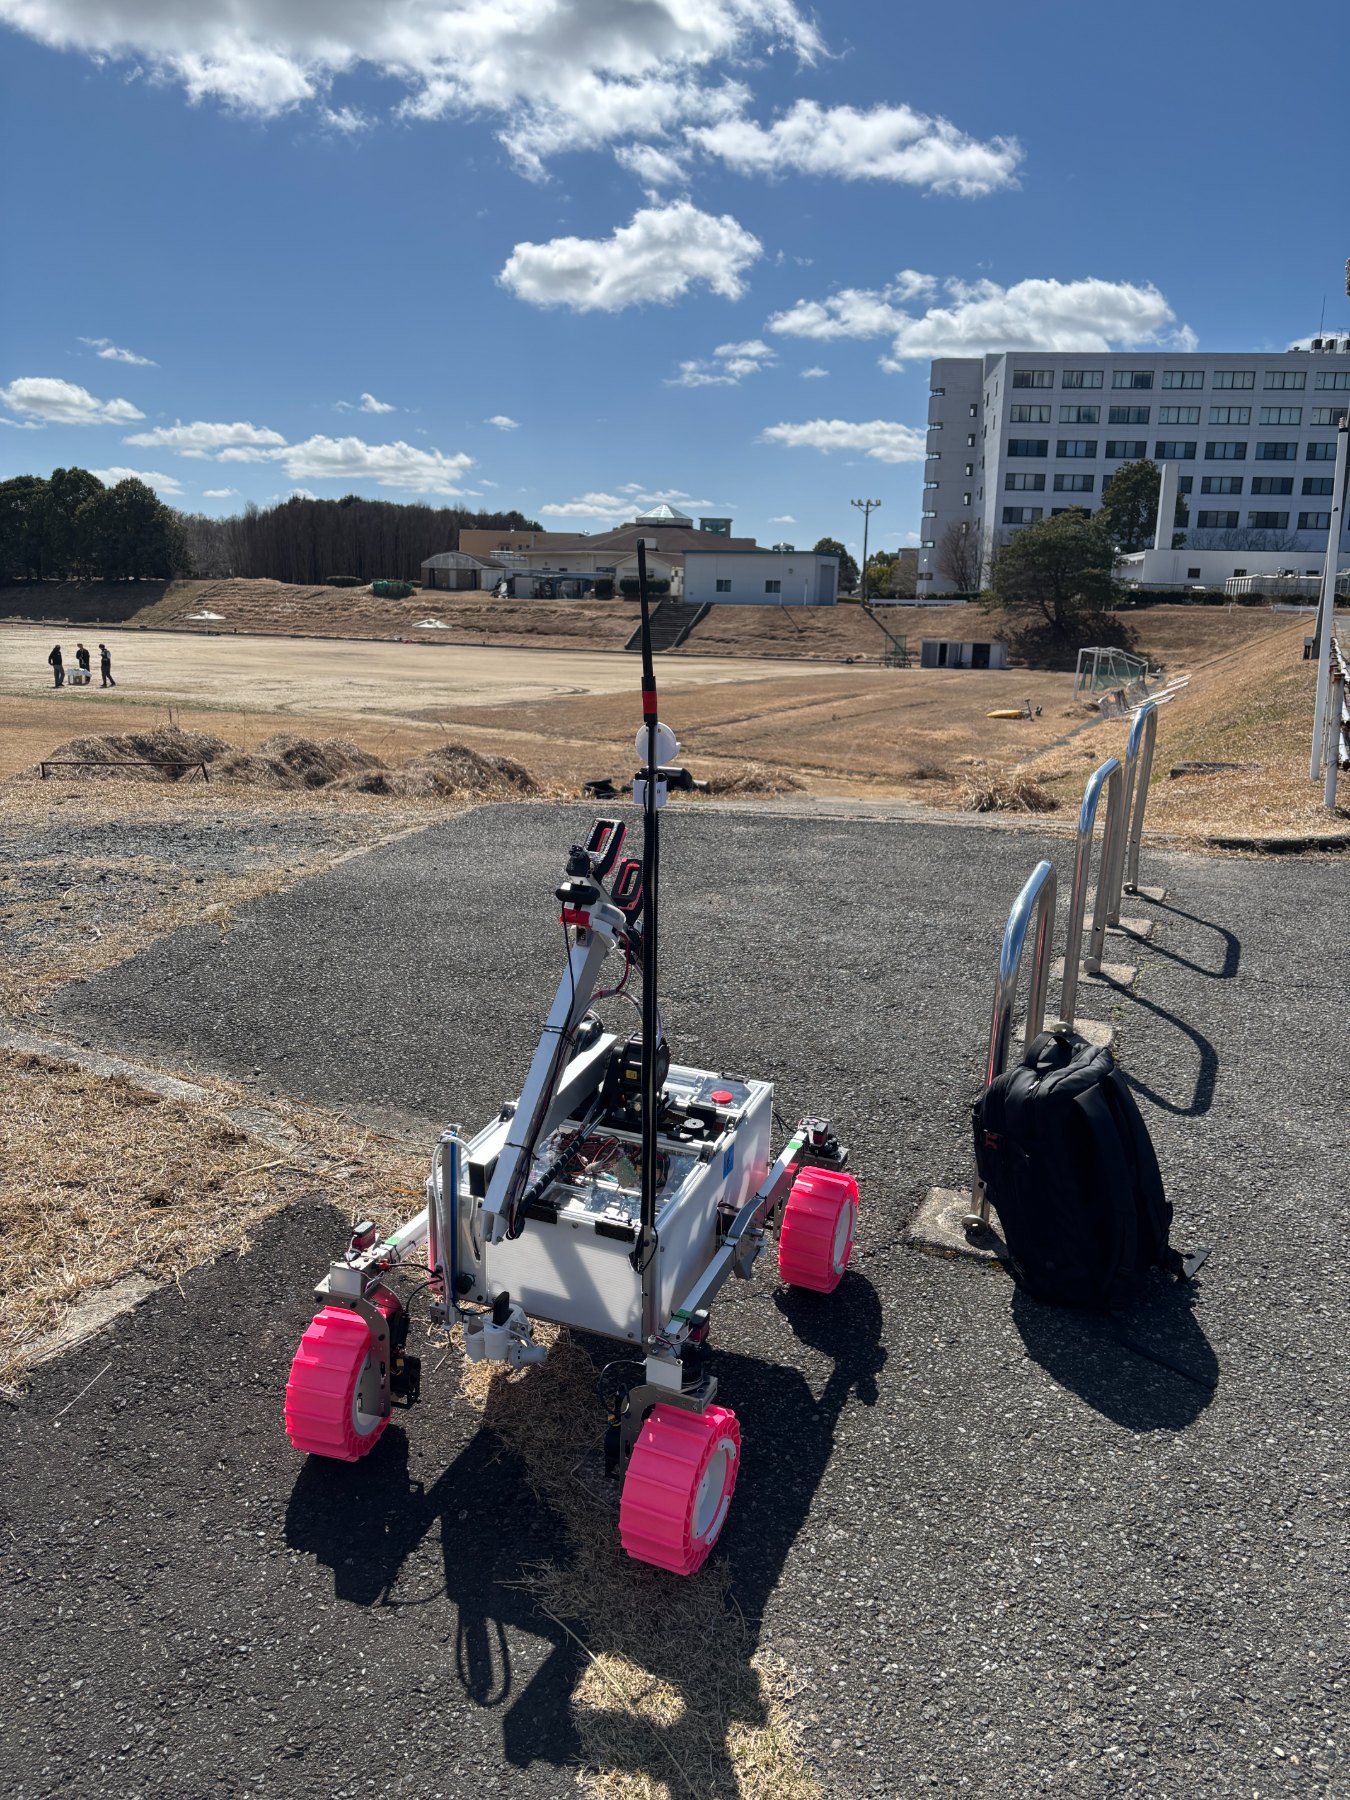
Joint driving test before the competition
About a week before the competition, we held a joint driving test with two other teams on the grounds of Tokyo University of Information Sciences. We rotated through three kinds of mission tests (autonomous control, unmanned construction and integrated exploration) and gave the rover a final check in outdoor conditions close to the real event.
2026.03.18
Shipping trouble and repairs on site
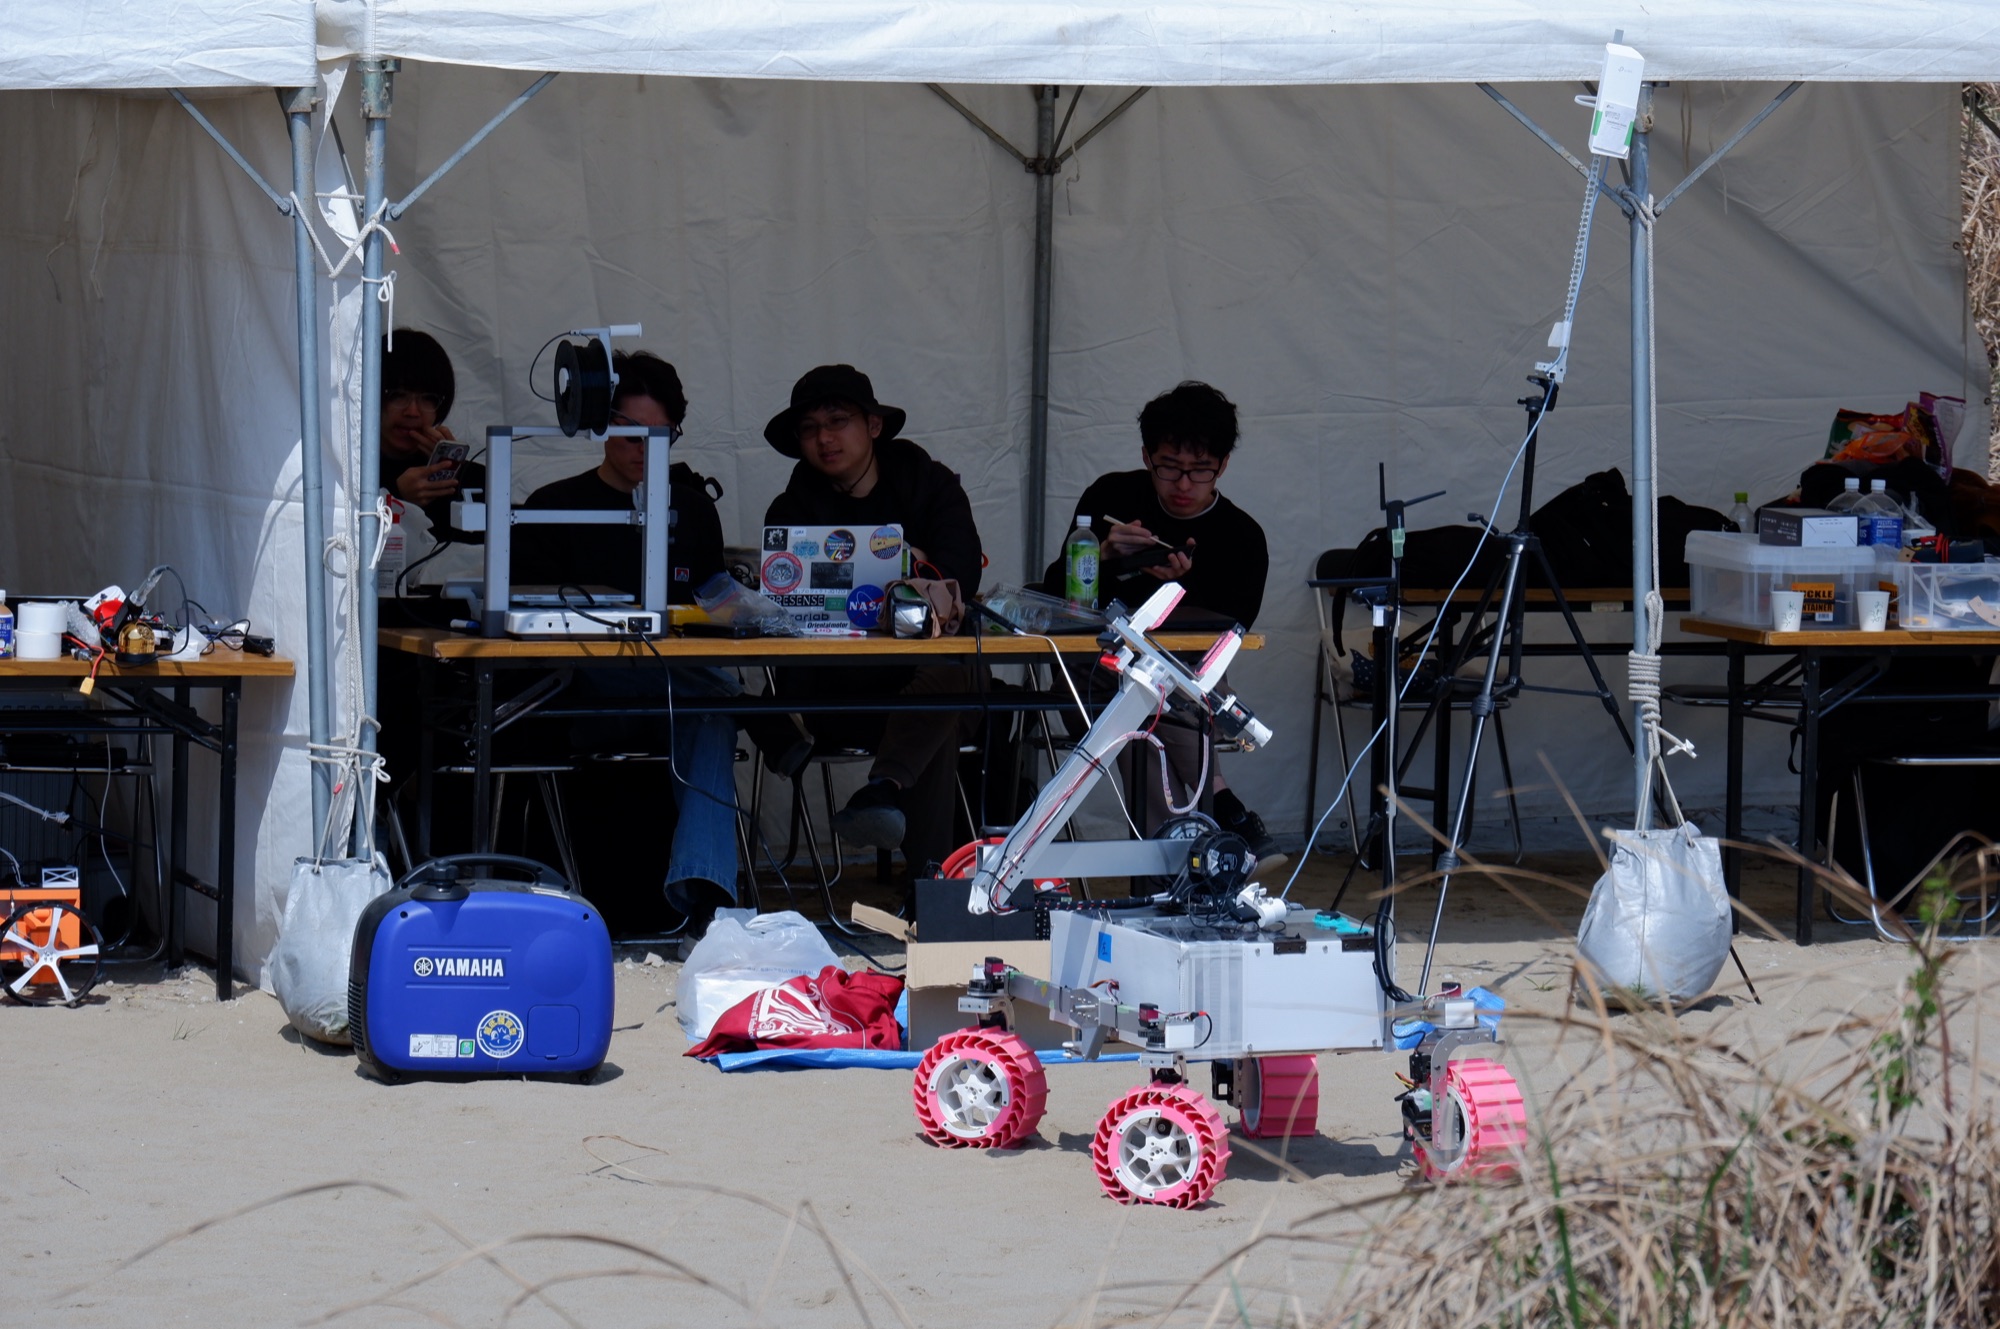
When we learned that the rover would not arrive until the first day of the competition, we changed the delivery point to a depot in Himeji, drove it to Tottori in a rental car, and made it in time for the test run on the afternoon of the 18th, our only chance to check it.
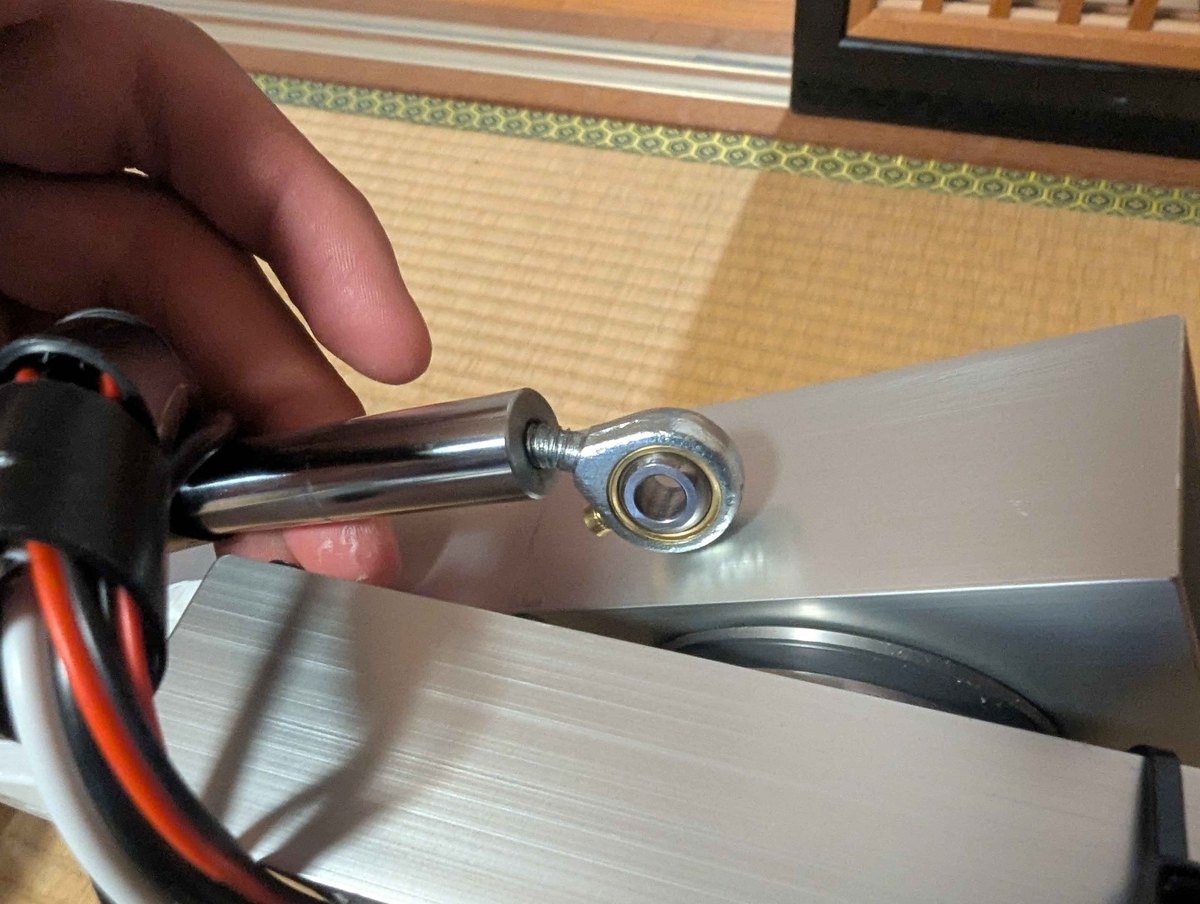
When we unpacked it, the rod-end bearings in the arm's drive had been badly bent by impacts during shipping. We bought eye bolts of a similar shape at a nearby hardware store, designed and printed adapter parts on the spot with the 3D printer we had brought, and got the arm working again.
2026.03.19
Technical inspection and tech exchange
The rover passed the technical inspection, which checks dimensions, weight, electrical systems and radio equipment compliance. At 35.35 kg, it was well under the 70 kg limit. In the evening we joined a technical exchange with other teams and heard first-hand about their design ideas.
2026.03.20
Qualifying: overcoming trouble on site
In scientific exploration, we photographed rocks, measured the temperature of the sand surface and at 5 cm depth, and imaged sand with the microscope scope. At the lander, we identified the faulty part from an AR code, then used the arm to press the power button and pull out the plug.
We also faced problems: a communication dropout right after the start, button indicator lamps that could not be seen on video in the strong sunlight, and sideways slipping on the slope. We switched to the backup link to resume driving, and on the climb we switched to reaching the goal as planned in advance. In the end, we finished 1st overall in qualifying, including professional teams.
2026.03.21
Final: carrying the 5 kg steel ball to victory
We changed our operation to establish communication during preparation and keep it up, fixed the video start-up problem, and went into the final. In unmanned construction, the 5-axis arm gripped one 5 kg steel ball after another and carried them all the way without dropping one.
The autonomous driving program we rewrote just before the competition worked correctly on the dunes, passing every waypoint autonomously. We completed the competition without any major breakdown and won the Entry Division.
Lessons
Lessons from the competition
Beyond the win, the competition made clear what to take forward to our next rover.
01
Dust protection
Sand got inside the rover every time we drove, and we had to take it apart and clean it every night. We will build dust protection in from the design stage.
02
Communication
Choosing the 5 GHz band helped avoid interference, but we still had a dropout right after the start. We are reviewing our connection procedure and how we use the backup link.
03
Visibility and attitude
Seeing the video in strong sunlight and knowing the rover's attitude on slopes were challenges. We are improving the cameras and the operator display.
04
Operations
We learned how much operations matter in competition, from managing power for the control PCs to checking scores for each mission.
Gallery
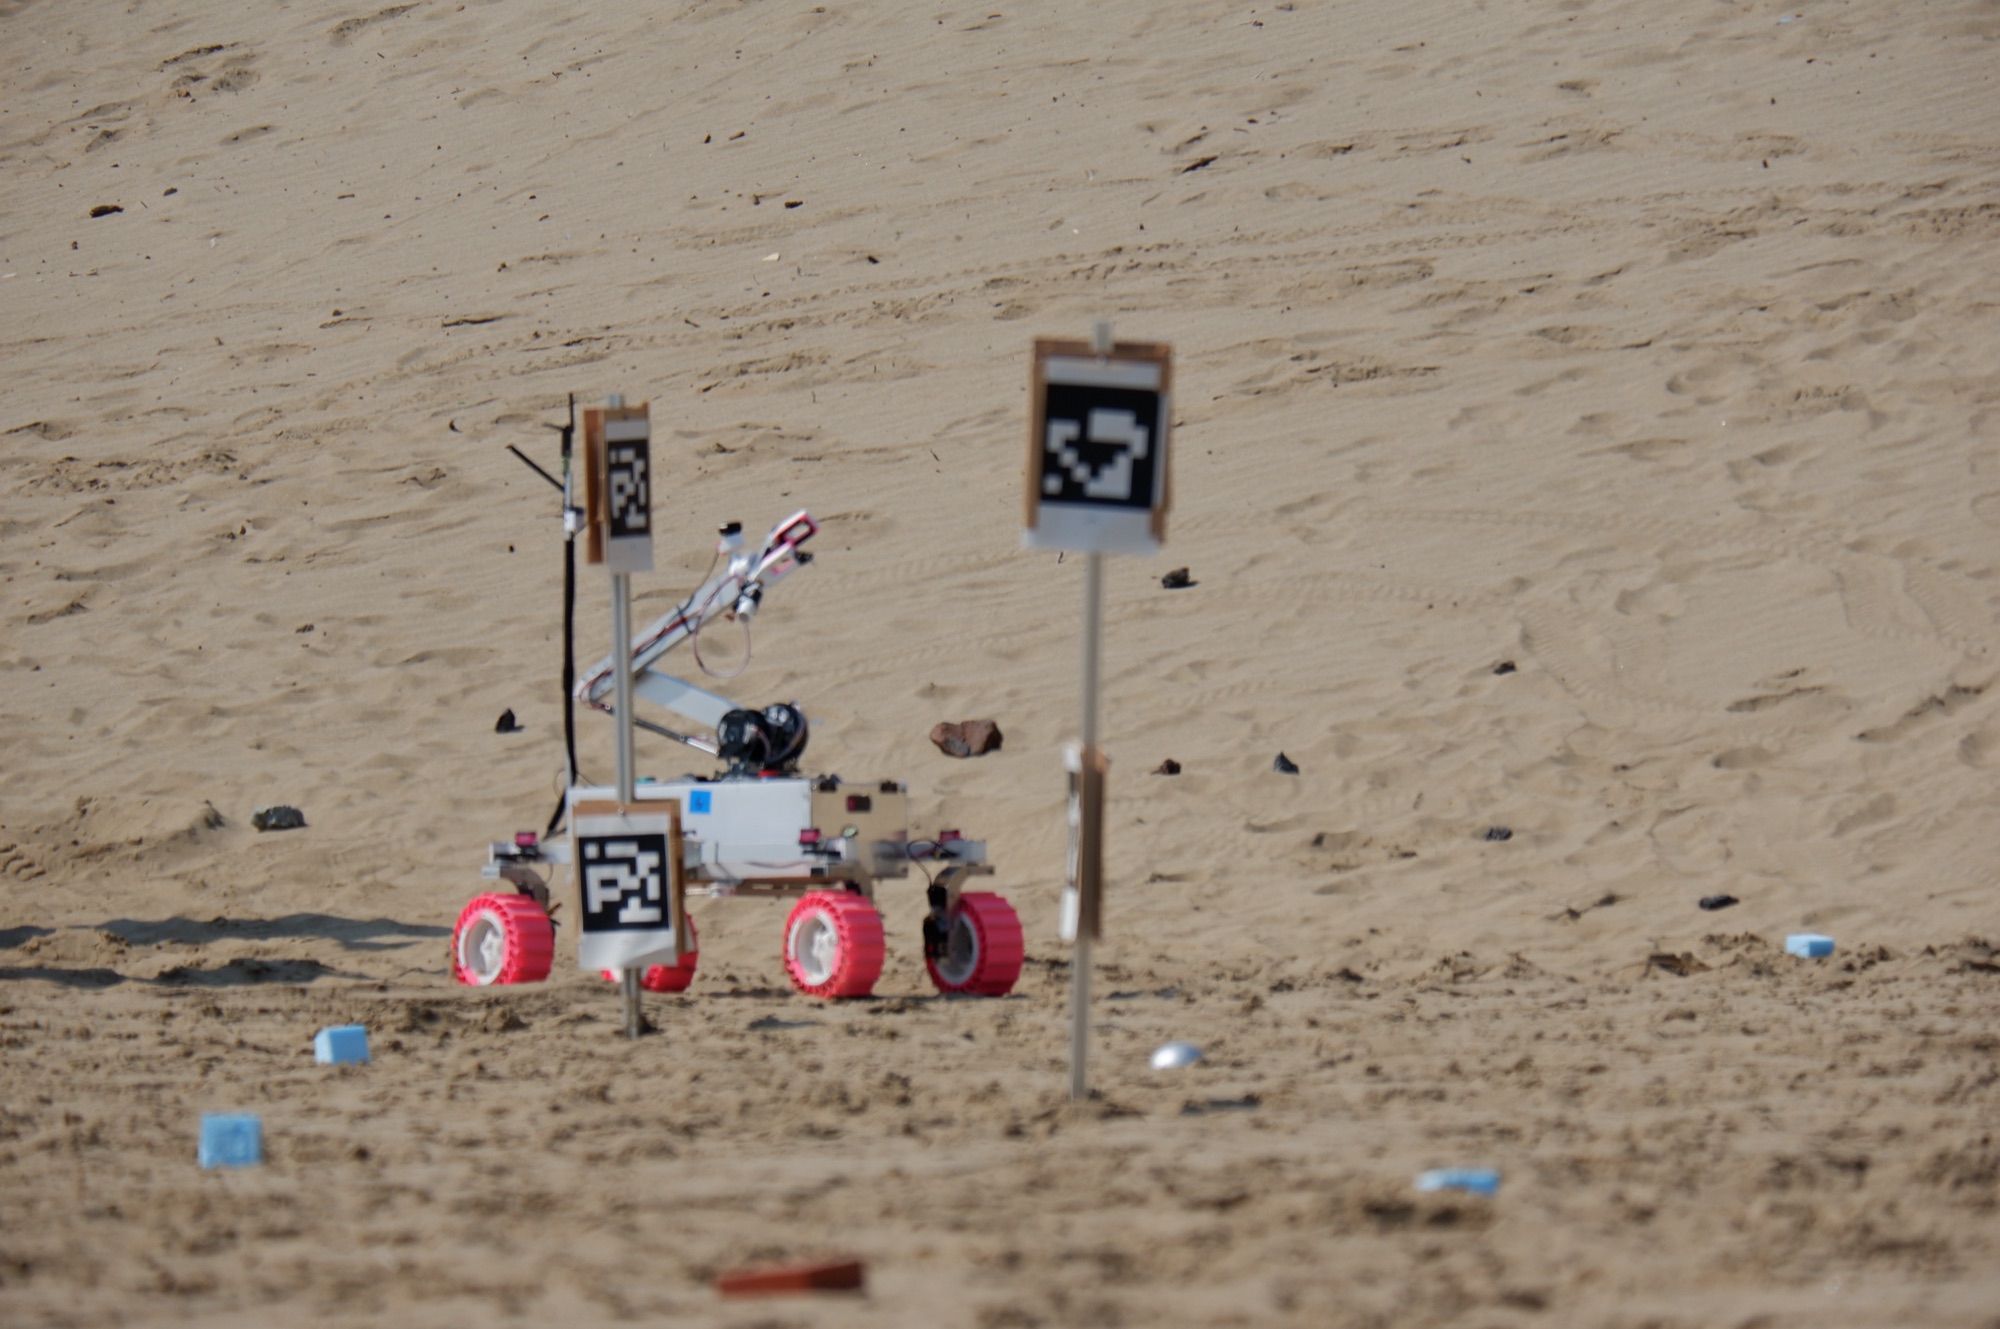
At the competition
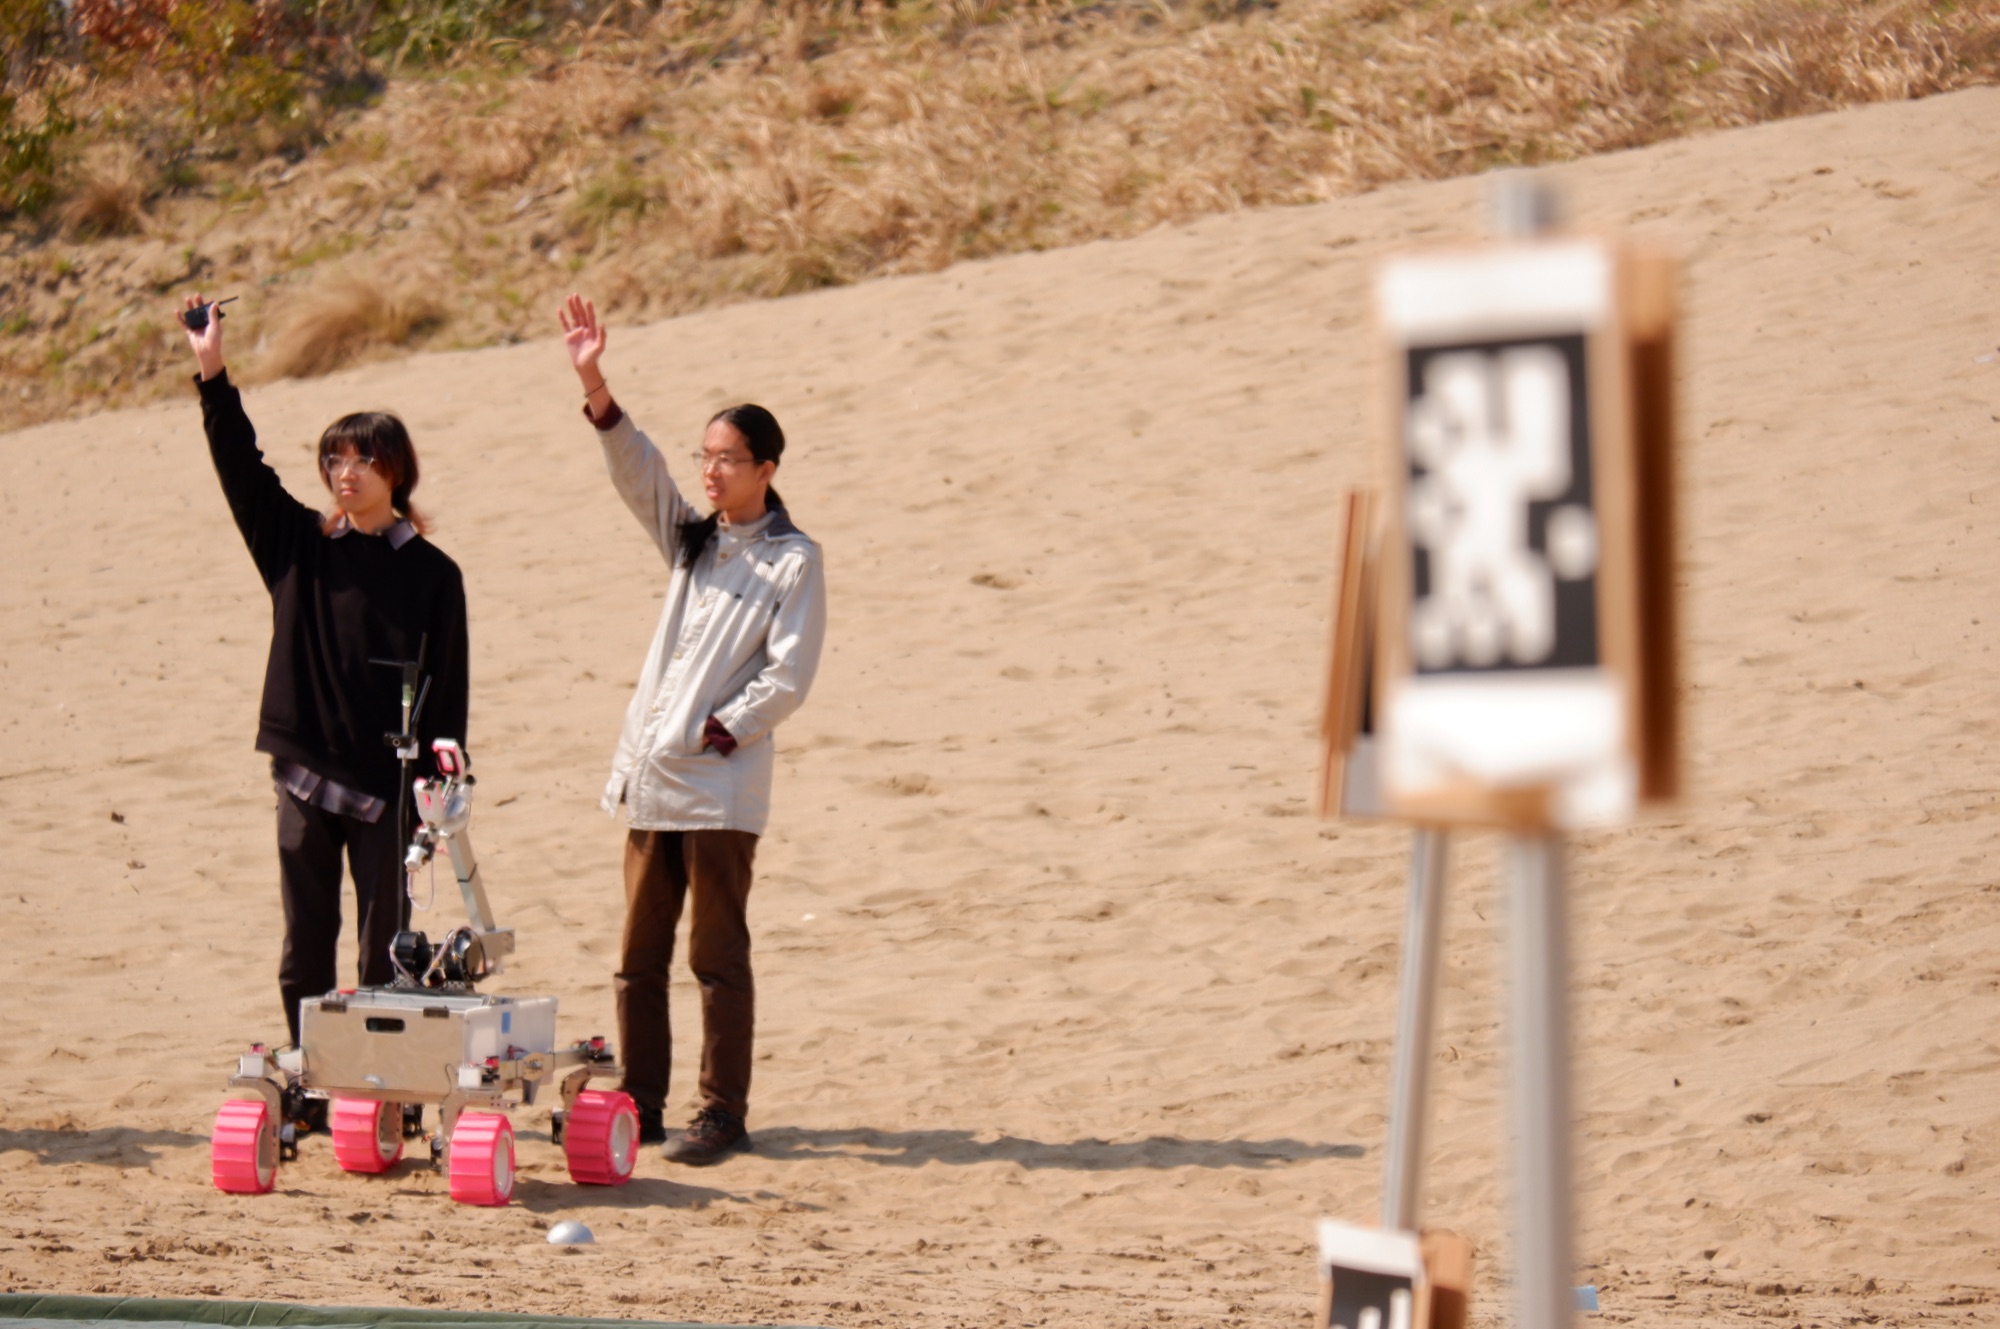
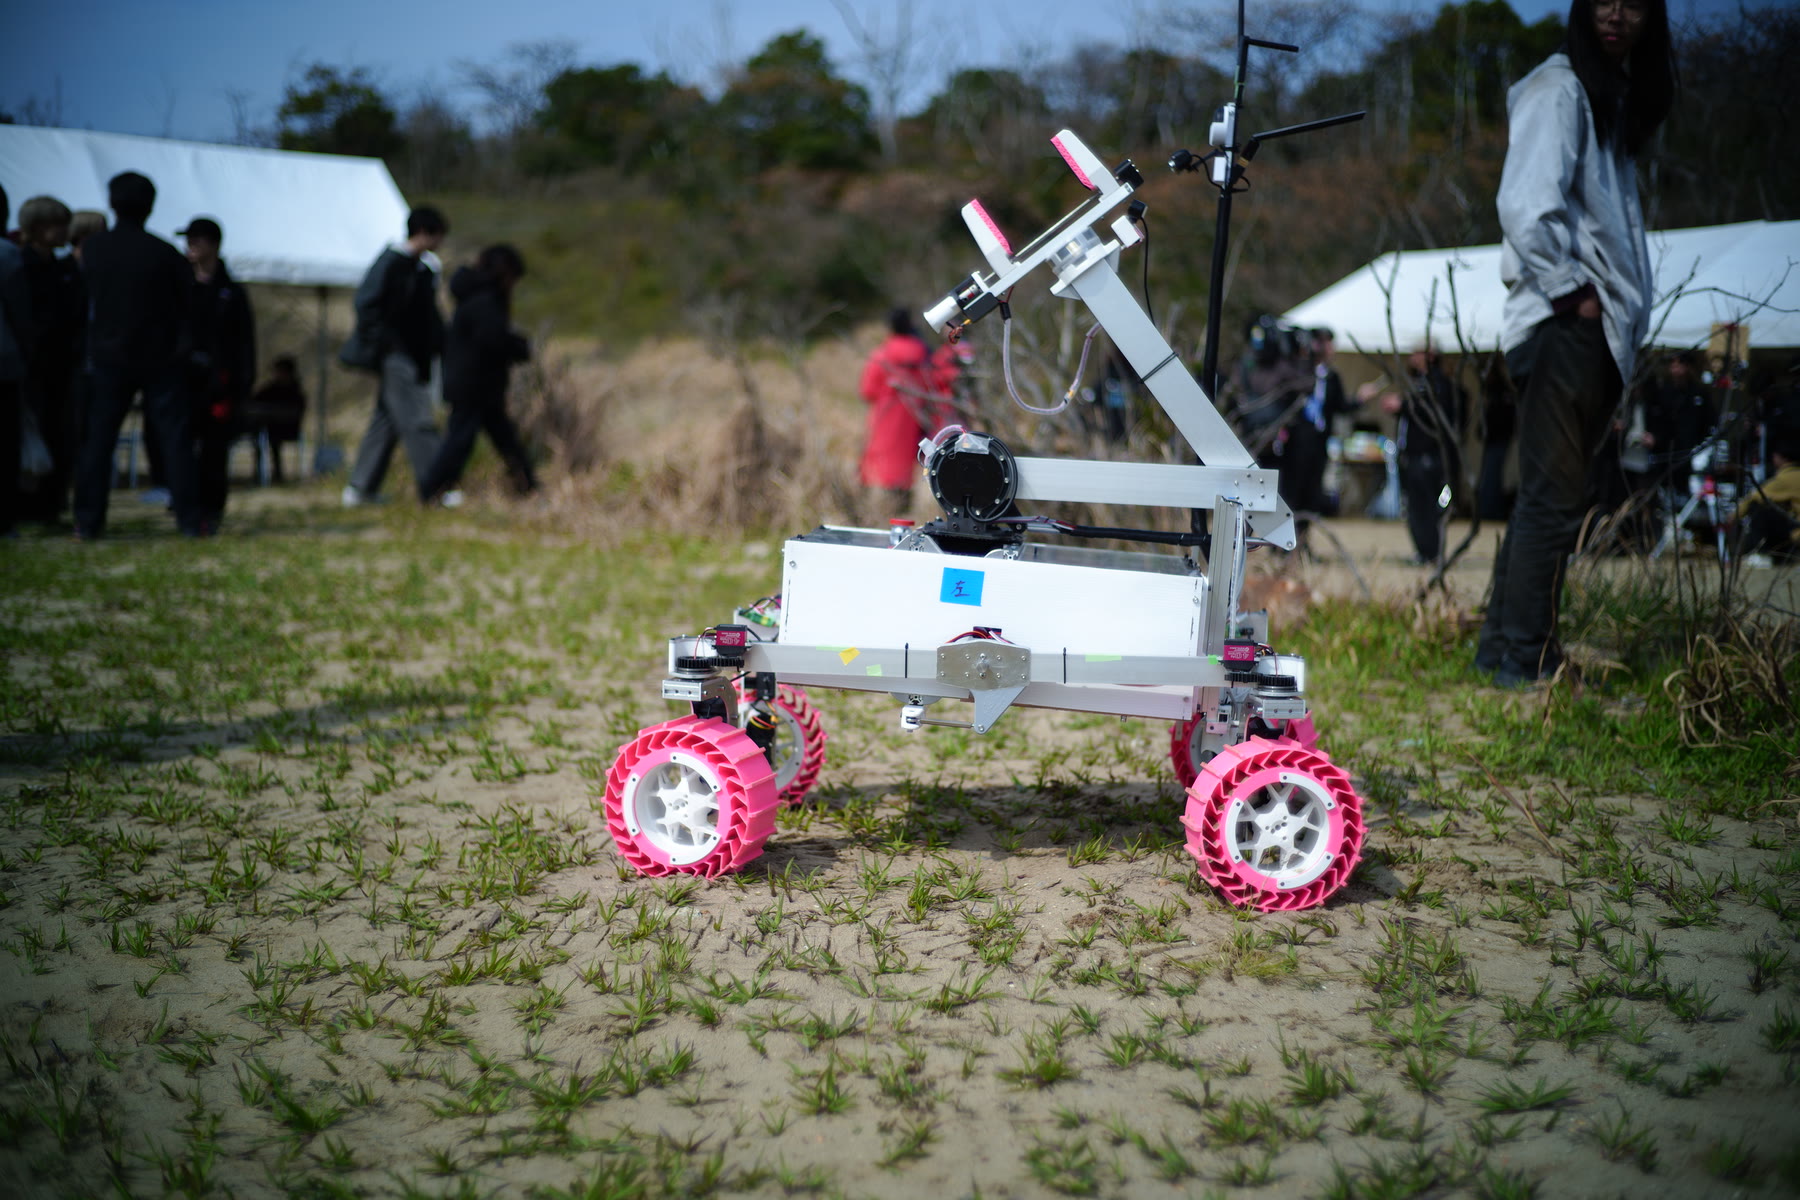
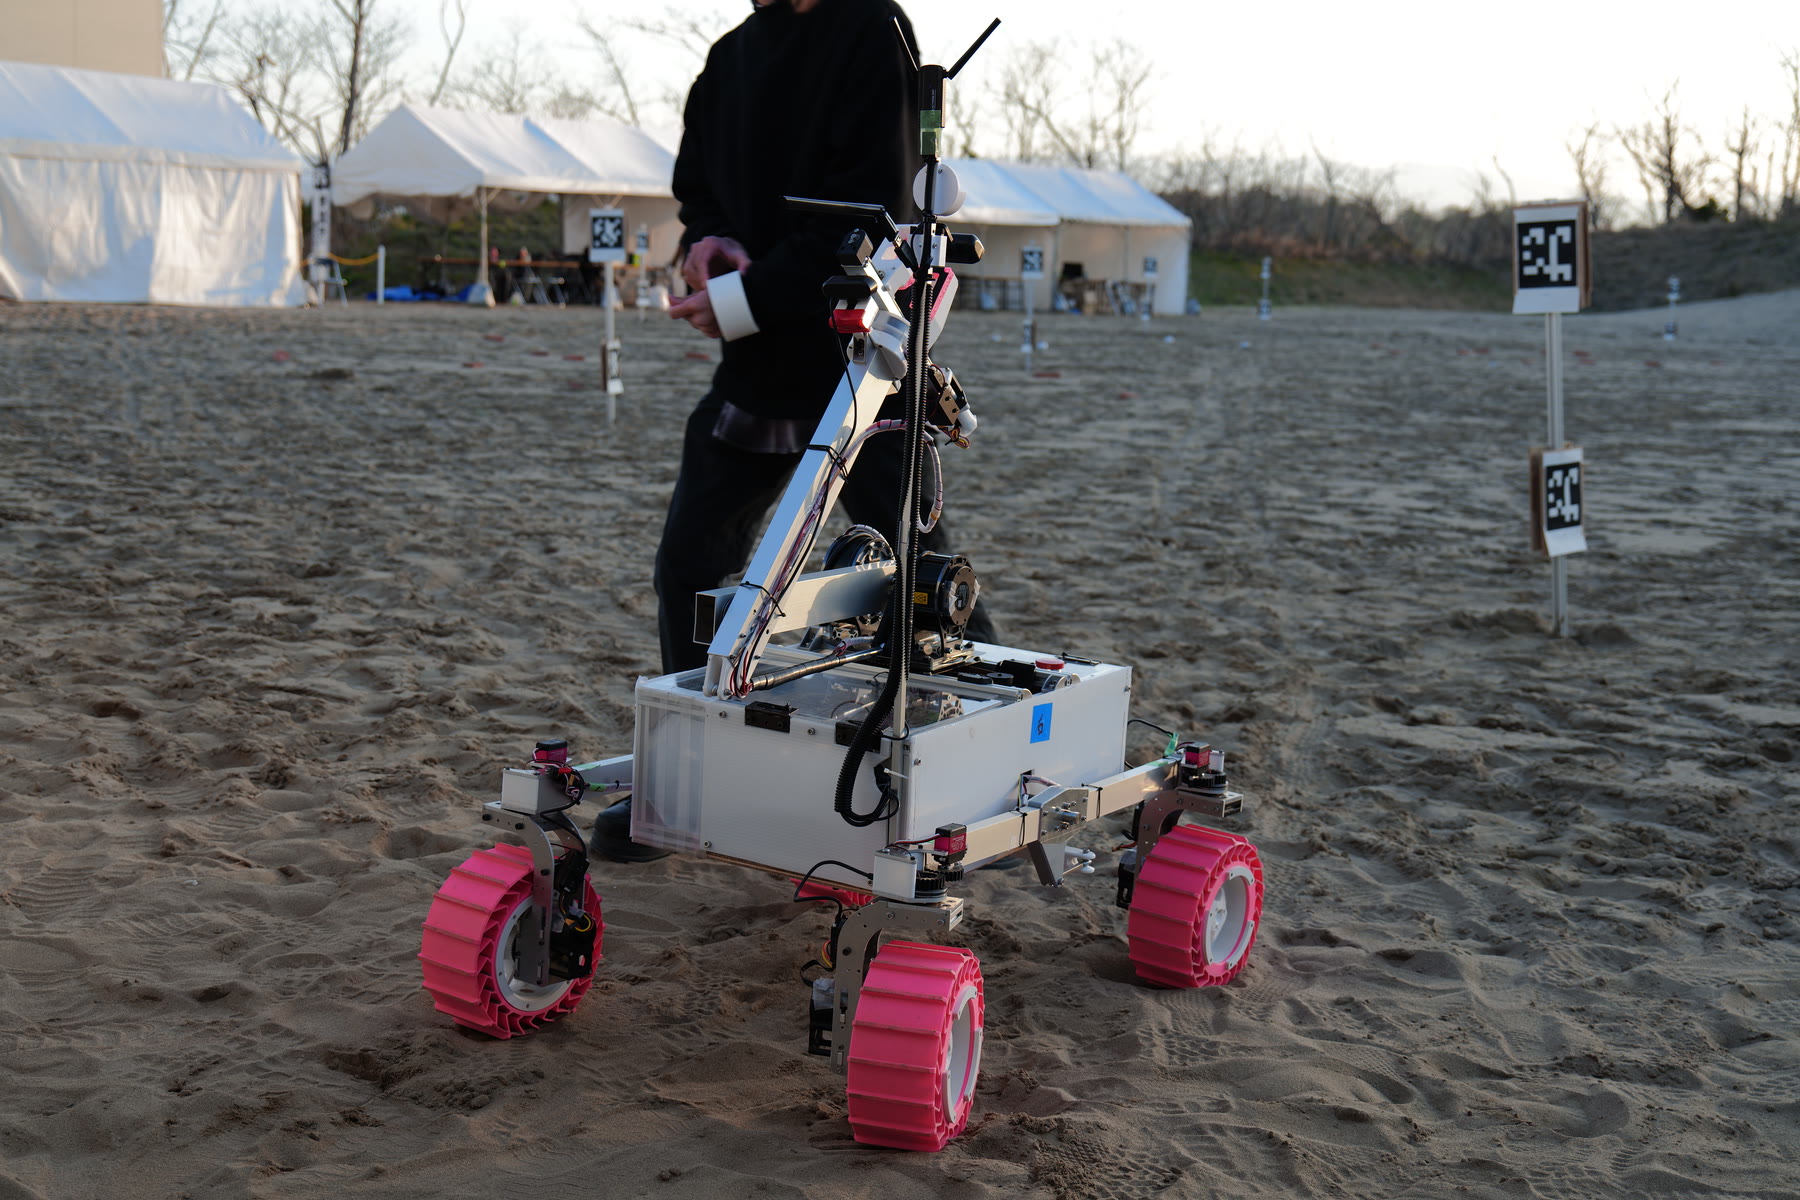
Next
Next: the Expert Division.
We are aiming for a top finish in the Expert Division of the Tottori Rover Challenge 2027 and a place in the finals of University Rover Challenge 2027.