Rovers
Rovers
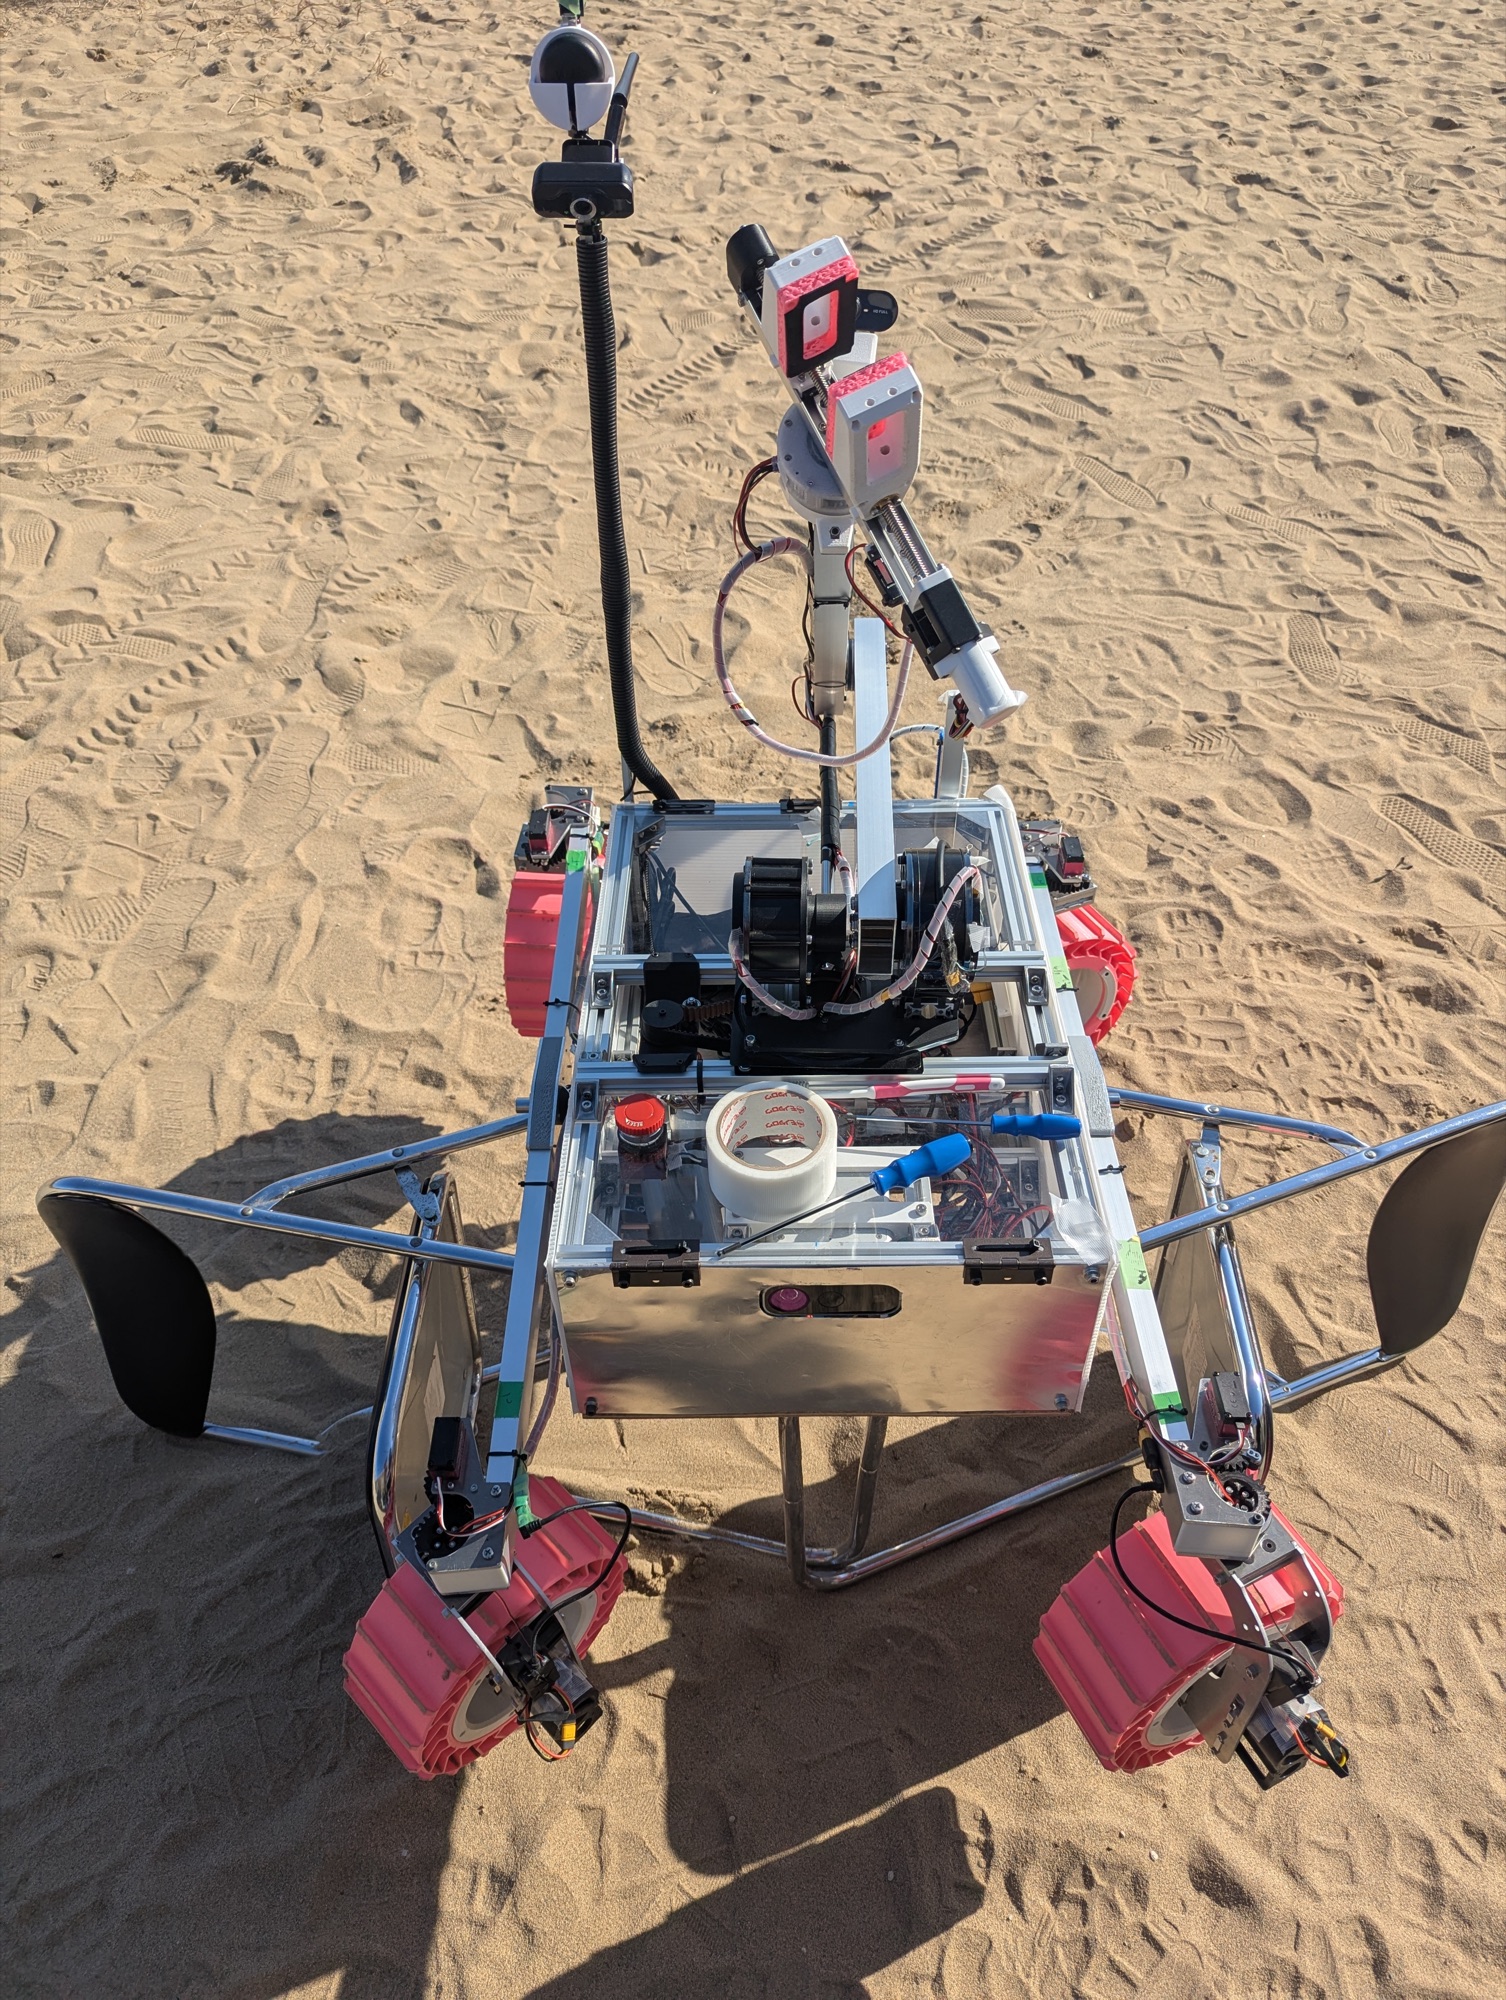
From the sand dunes to the field. The planetary exploration rovers designed and built by TSUKUBA ROVER TEAM.
Lineup
Two rovers
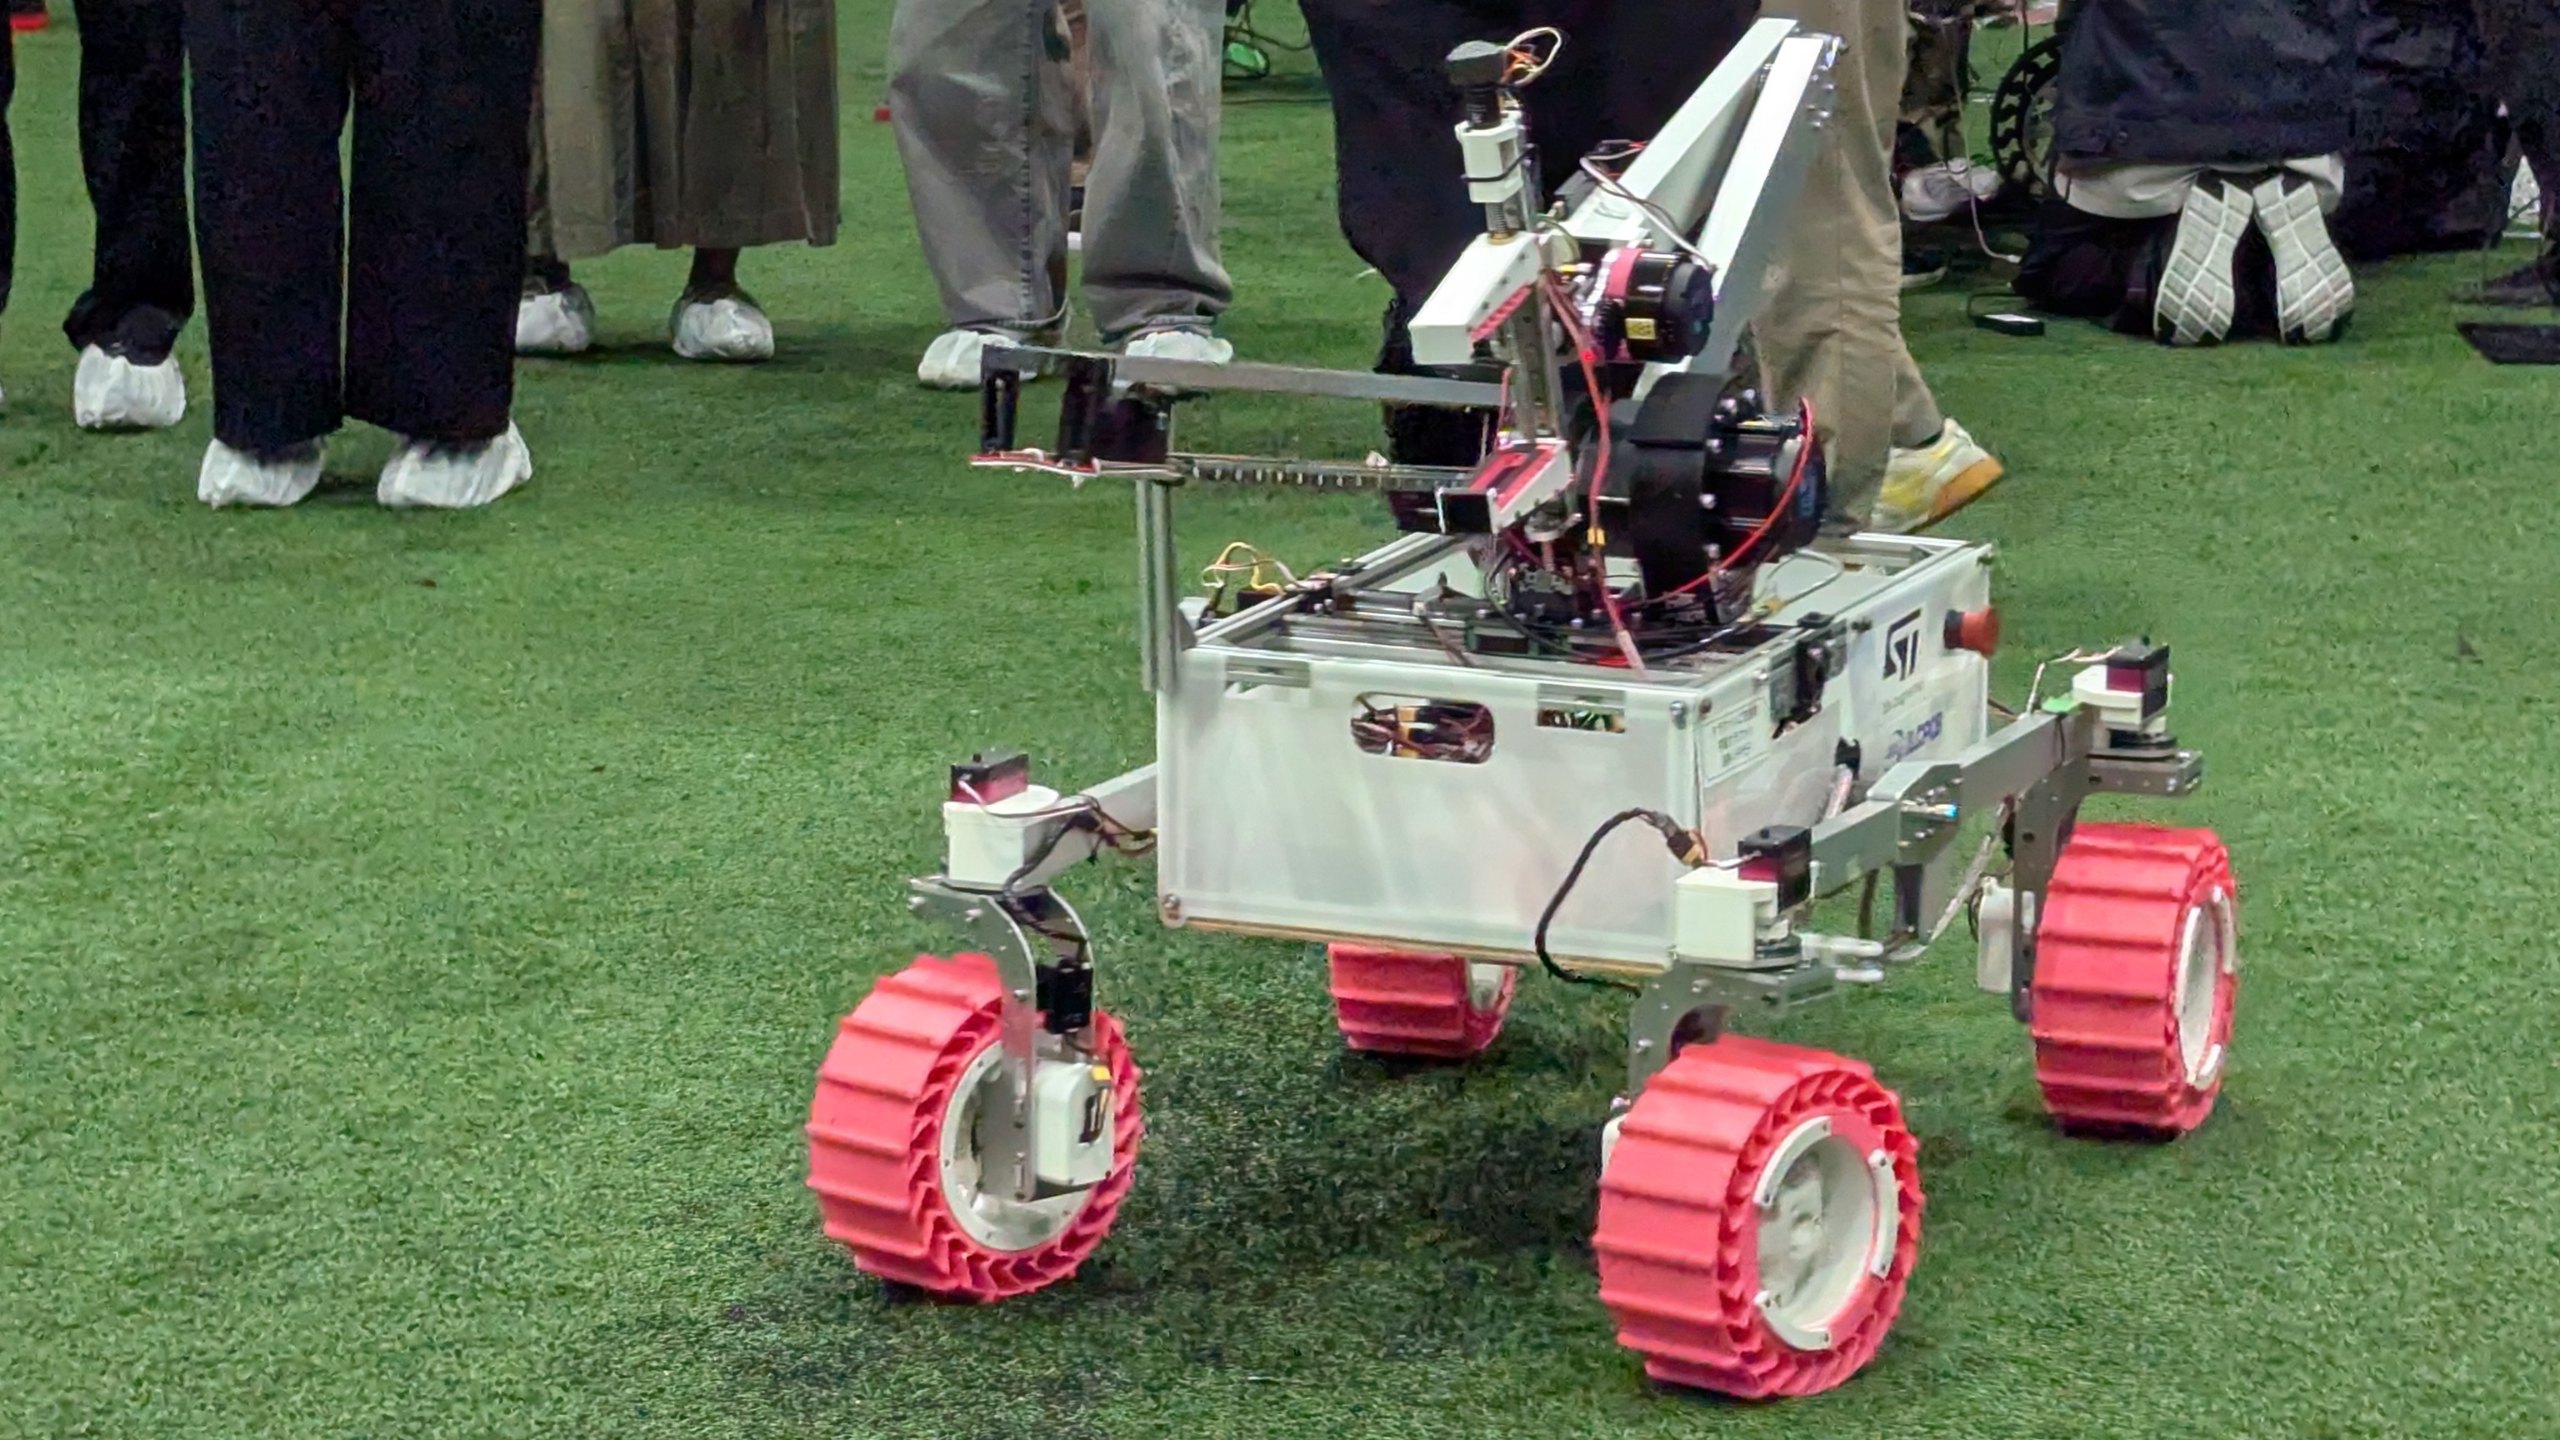
Rover 02 · 2026
TR-2
Our second rover, in development with URC 2027 in mind. Building on TR-1 with upgraded servos, arm and microcontroller, it won the Space Rover Cup 2026.
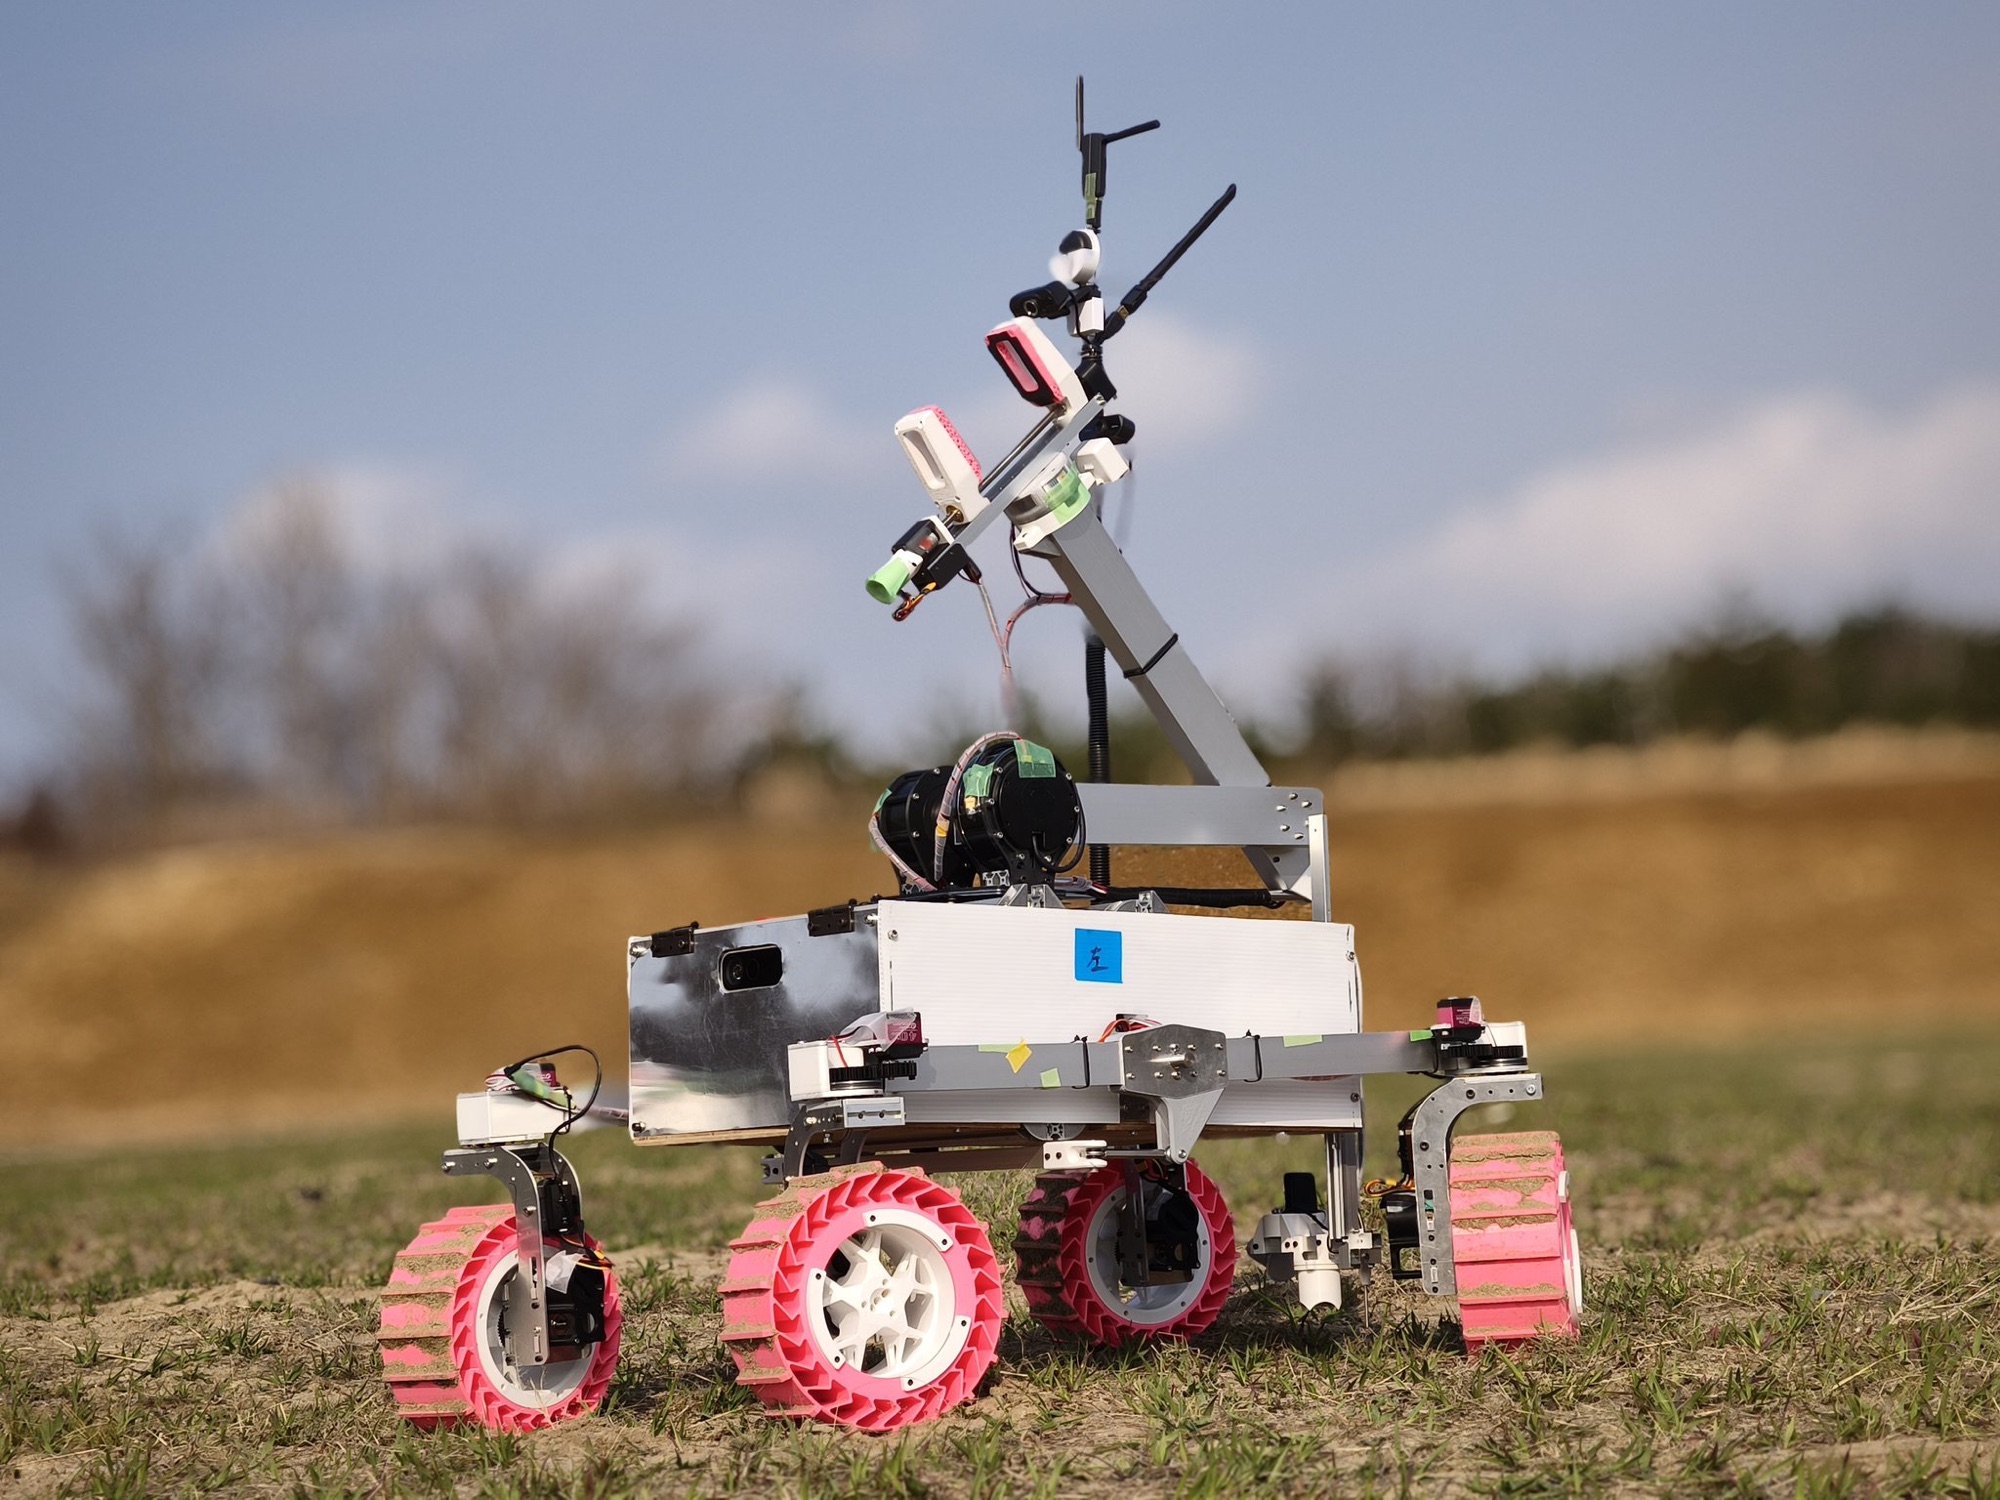
Rover 01 · 2026
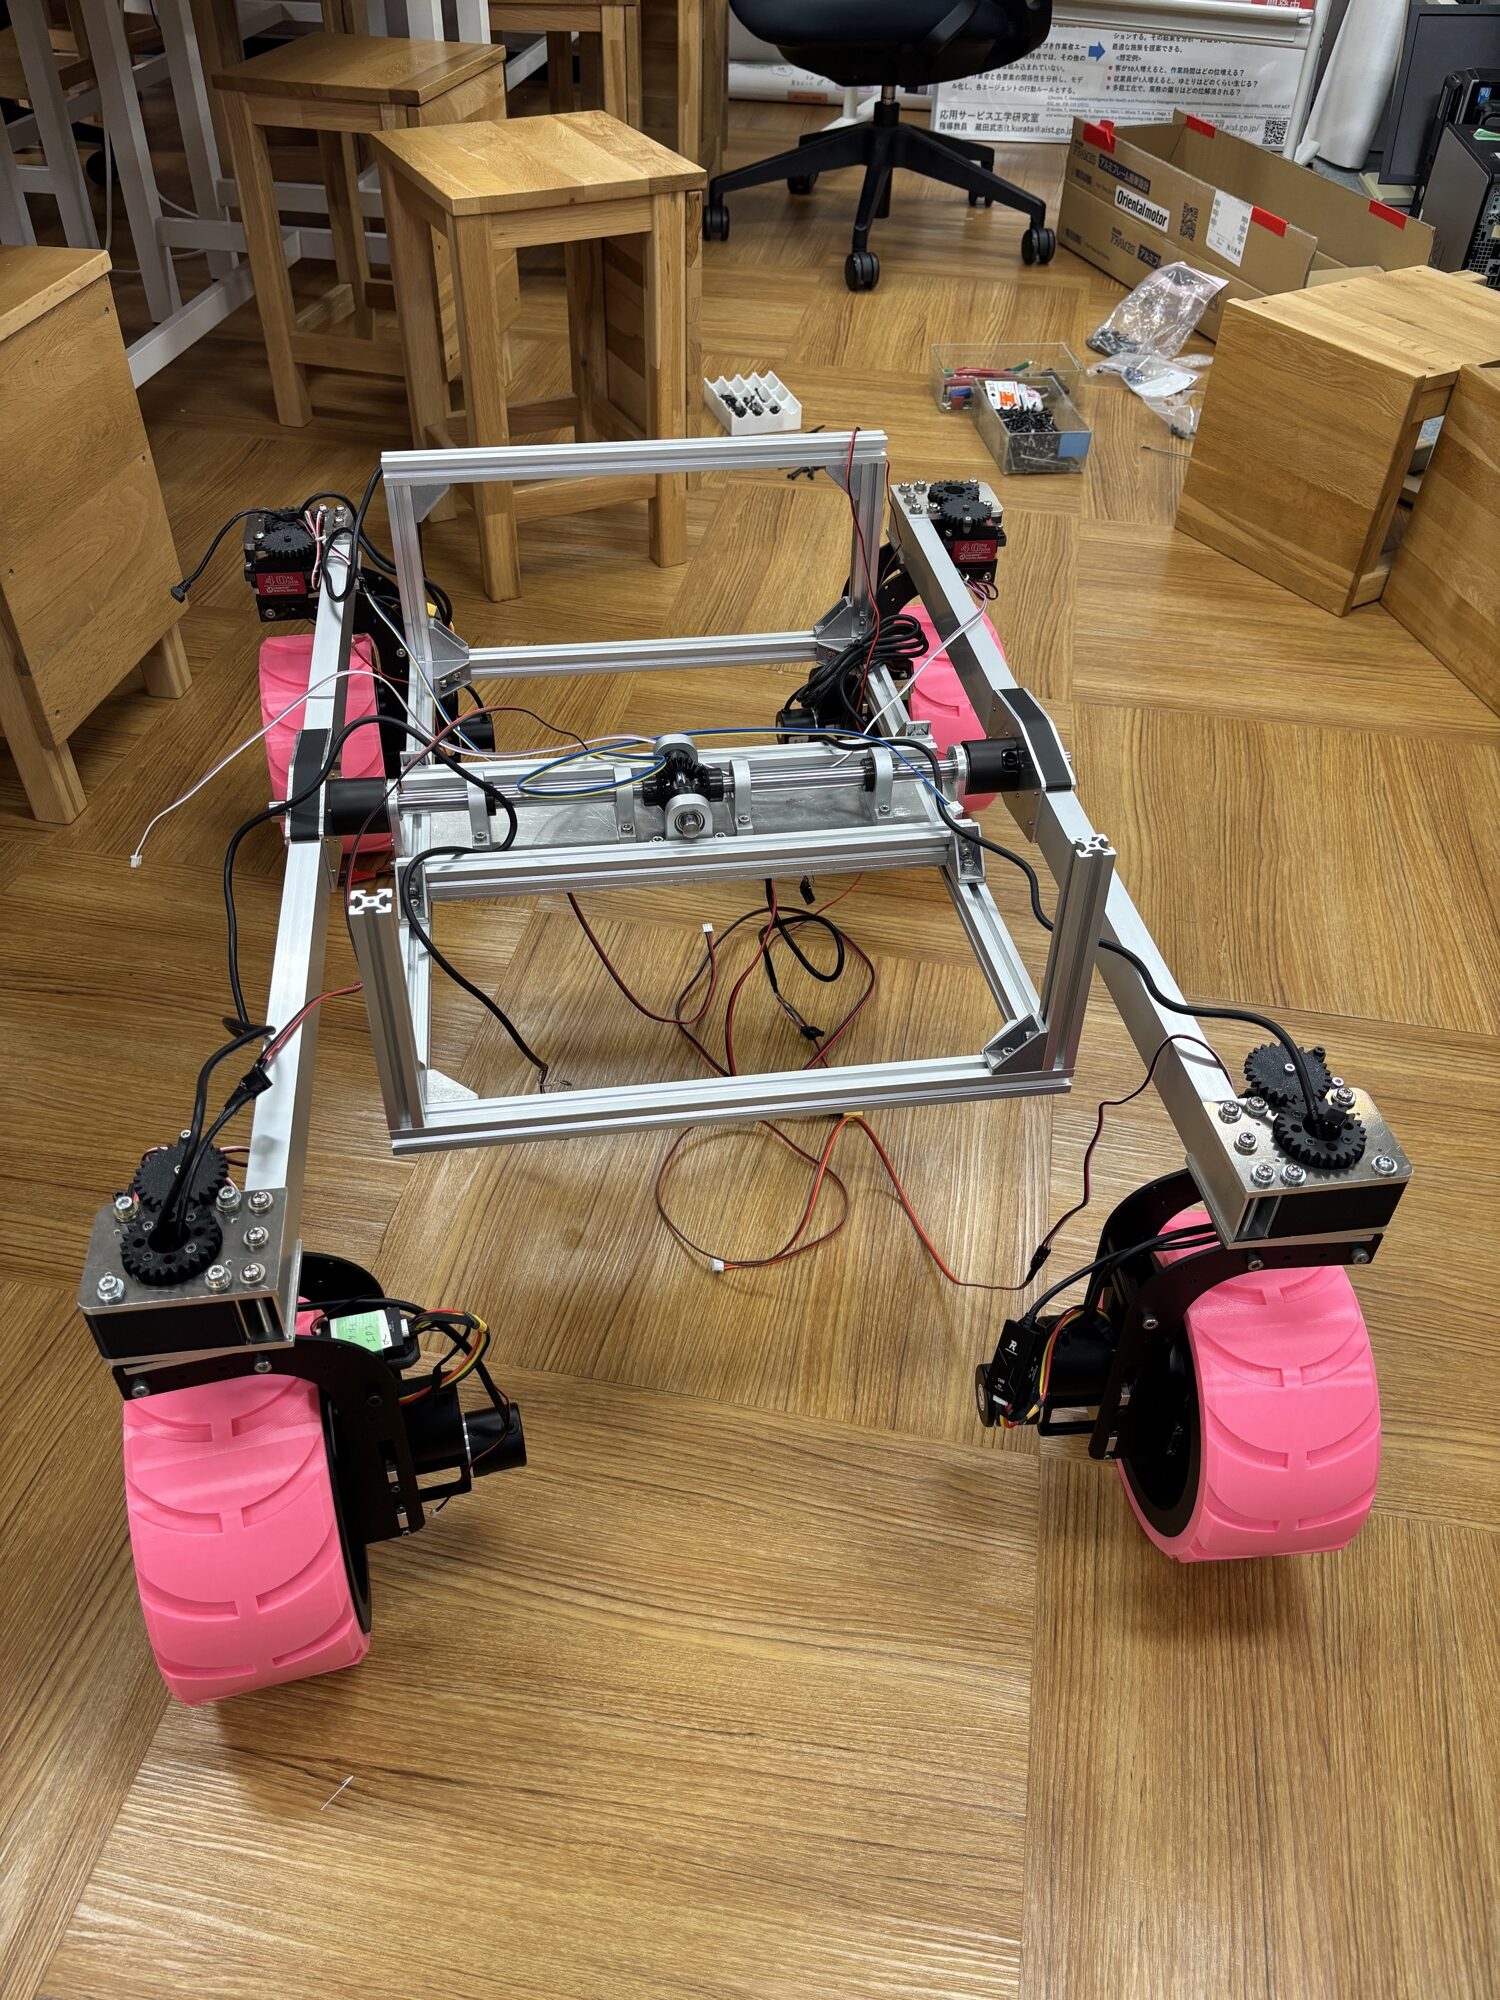
TR-1
Our first rover, developed in about six months. With 4-wheel independent steering and a 5-axis arm, it won the Entry Division at the Tottori Rover Challenge 2026.
Compare
TR-1 and TR-2
TR-1
TR-2
Competition
Tottori Rover Challenge 2026
Space Rover Cup 2026
Result
Entry Division winner
Winner
Size (stowed)
684×1010×900mm
684×1010×900mm
Weight
35.35kg
approx. 37 kg
Servo motors
80kgf
160kgf
Arm
5-axis (4 DOF + gripper open/close)
Stronger joint torque, parallel motion via a linear mechanism
Microcontroller
Teensy 4.1
STMicroelectronics
Reducer
—
In-house cycloidal reducer (1:9)
Drive and power
4-wheel independent steering, 22.2 V LiPo
Same as TR-1
Open source
Software and PCB data
We manage our programs and PCB design data on GitHub.